NASA KSC Surface Autonomy Test Site
NASA/Frank Micheaux. Public domain (NASA / US government work).
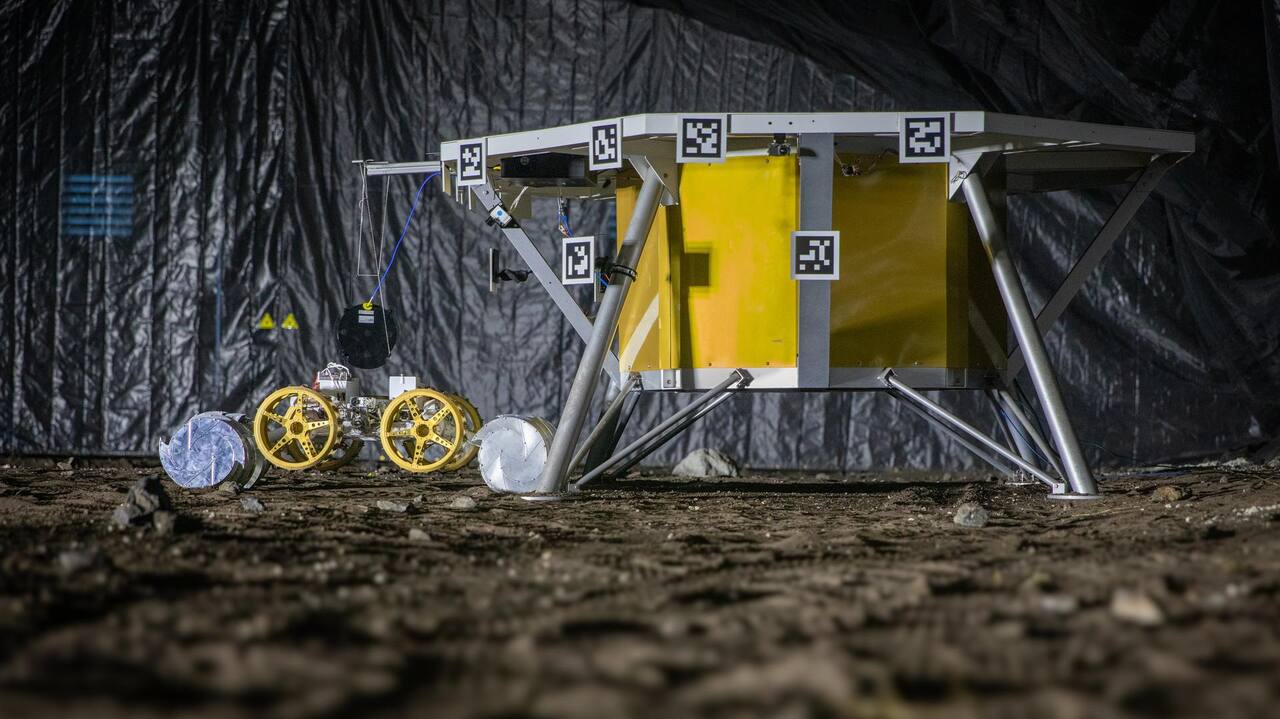
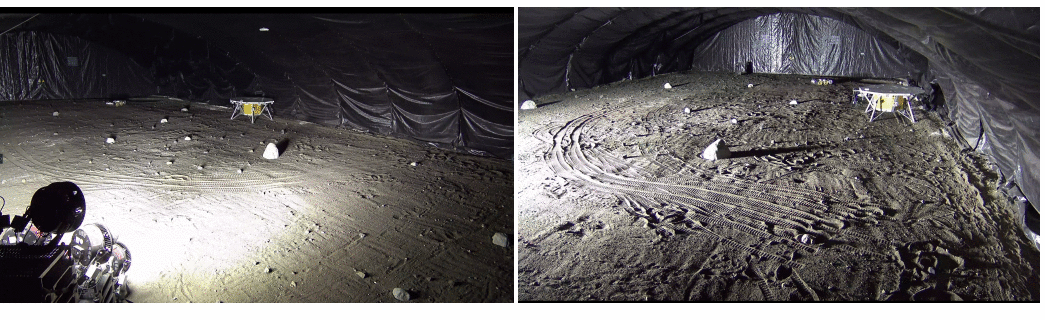
An enclosed, blacked-out analogue site at NASA KSC built by the ISRU Pilot Excavator project to test vision-based surface autonomy under lunar south pole illumination geometry. The article under test drives on prepared soil under six narrow beam stadium lights, navigates against a full-scale mock lander carrying fiducials, and is tracked by a 36 camera motion capture system whose pose solution is published as independent ground truth [1]. The site is listed by the KSC partnerships office as the Surface Autonomy Test Site [2].
Laboratory data
Section titled “Laboratory data”| Parameter | Value |
|---|---|
| Operator | NASA KSC, ISRU Pilot Excavator project, STMD Game Changing Development |
| Location | NASA KSC, Florida, United States, 183 m east of the IPEx flight control building |
| Commissioned | Not published. First documented campaign August 2024 |
| Type | Enclosed analogue surface site, blacked out, artificially lit |
| Floor area | 39.6 x 21.3 m structure, 843 m2; practice area 33.5 x 21.3 m, 714 m2 |
| Capabilities, area | Practice area, soil bed and rock field |
| Capabilities, fixtures | Lighting, mock lander |
| Simulant or terrain | Local Florida soil, tilled; albedo 0.26; baseline penetrometer resistance 0.5 kg/cm2 |
| Instrumentation | 36 OptiTrack Slim x13 motion capture cameras; 4 Axis situational cameras; Geotester penetrometer |
| Ground truth | OptiTrack beacon pose on a ROS topic, logged against vehicle telemetry |
| Fidelity limits | 1 g, ambient atmosphere, terrestrial soil, no vacuum |
| Access | KSC partnerships office, Testing and Laboratories; no lead time or fee schedule published |
| Cited by | IPEx |
The site was built and is operated by the ISRU Pilot Excavator project under Space Technology Mission Directorate Game Changing Development [4]. The KSC partnerships office catalogs it as the Surface Autonomy Test Site, alongside the Granular Mechanics and Regolith Operations laboratory and its Artemis Arena and ASSIST chamber; the operators’ own engineering name for it is the IPEx Autonomy Test-Site [2]. Temperature and humidity sensors are distributed through the site and reported over the site network, but nothing sets them. A Ubiquiti AirFiber radio link connects the site to the control building, with a local server ingesting situational imagery and running the OptiTrack and network video recorder software so that only tracker pose and compressed imagery cross the link; article Wi-Fi is routed through an access point on the mock lander, and all network equipment is on uninterruptible supplies.
Capabilities
Section titled “Capabilities”Enclosed practice area
Section titled “Enclosed practice area”| Parameter | Value |
|---|---|
| Working volume | Structure 39.6 x 21.3 m, 1.8 m sidewall, 6.1 m ridge; practice area 33.5 x 21.3 m |
| Test article limits | Largest article run: the 30 kg-class IPEx alpha configuration |
| Vacuum | Not applicable. Ambient Florida pressure and humidity |
| Temperature | Not controlled. Measured and reported, not set |
| Illumination | See the lighting; blackout panels block 95 percent of daylight |
| Simulant or terrain | Local Florida soil, tilled level; see the bed |
| Slope | Not applicable. The bed is prepared level |
| Gravity offload | Not applicable. 1 g |
| Instrumentation | 36 OptiTrack Slim x13 cameras on the perimeter; 4 Axis situational cameras |
The enclosure is a fabric-covered galvanized tube structure. With blackout end panels installed and the two staging foyers curtained off, the usable rover practice area is 33.5 x 21.3 m [1][2]. Slope work on IPEx wheels is run separately in the GMRO Regolith Test Bed [5].
Site selection ran as two trade studies. The first compared KSC, Cape Canaveral Space Force Station and off-center land, and selected KSC on logistics. The second compared available real estate at KSC against existing buildings and settled on open ground 183 m east of the IPEx offices, which sets the ground control separation used during operations [1].
The structure requirement was an interior dark enough to stand in for the lunar sky, so that artificial lighting is the only source, combined with a Florida climate envelope covering humidity, rainfall, moisture accumulation and lightning protection, a hurricane rating, and Authority Having Jurisdiction fire and exit compliance. Lean-to structures, brick and mortar buildings, portable structures and hybrids such as CONEX box walls under a rolled steel arch roof were considered before a fabric-covered galvanized tube tent was procured.
Blackout is achieved with tarps suspended from the tubular trusses that run the width of the structure, and with split curtains at each end that separate the practice area from the staging foyers and seal in the center with black Velcro. More opaque panel material was available but not bought.
| Blackout parameter | Value |
|---|---|
| Truss spacing | Every 3 m across the structure width |
| Panel material | 95 percent light-blocking polyester weave |
| Cost of more opaque material | Above 40 percent price premium |
| Panel drape | About 25 cm down from the ridge at the center of each panel |
Lunar illumination system
Section titled “Lunar illumination system”| Parameter | Value |
|---|---|
| Illumination | 6 RuggedGrade StadiumPro IV fixtures, 1400 W each, 5000 K, 200,200 lm, 20 degree beam |
| Working volume | Fixtures at one end of the 33.5 x 21.3 m practice area |
Measured illuminance falls steeply across the practice area. The narrowest available 20 degree beam was chosen to sharpen shadow edges [1]. Varying solar elevation and azimuth is listed as future work.
| Measured illuminance | Horizontal | Vertical |
|---|---|---|
| 30 cm from the lights | 78,000 lux | 192,000 lux |
| Sunward face of the largest rock | 9,500 lux | n/a |
| Foot of the lander | 360 lux | 2,345 lux |
| Far end of the structure | 94 lux | 850 lux |
The lighting configuration was selected by simulation before procurement. A model built in the Unity engine with the high definition rendering pipeline was used because HDRP accepts physical photometric units and reports resulting illuminance, so candidate layouts could be scored for uniformity and shadow sharpness against a simulated lunar sunlight baseline. The six fixture StadiumPro IV layout was adopted as the compromise.
| Lighting alternative considered | Outcome |
|---|---|
| Single Clar Illumi Max 300 LED, 132,000 lux at 0.5 m, 5600 K | Adequate for short range work, did not cover the area |
| 48 fixture layout | Improved uniformity, destroyed shadow quality |
| ARRI Daylight 18 kW metal halide | High intensity from few fixtures, costly and hard to integrate |
Public domain (NASA / US government work).
Prepared soil bed and rock field
Section titled “Prepared soil bed and rock field”| Parameter | Value |
|---|---|
| Simulant or terrain | Local Florida soil, tilled loose; albedo 0.26; baseline resistance 0.5 kg/cm2 |
| Working volume | The 33.5 x 21.3 m practice area floor |
| Temperature | Not controlled |
| Instrumentation | Geotester pocket penetrometer, run as a survey after a campaign |
The terrain is native Florida soil rather than a simulant. Preparation removes rocks above 7.6 cm and all vegetation and leaves a loose tilled surface resembling plowed earth, and penetrometer surveys run after the TRL 5 demonstration found that trafficked ground compacts to roughly twice the resistance of undisturbed ground, that the dig site compacted by as much as a factor of 11 from the 0.5 kg/cm2 baseline, and that the dump site loosened by a factor of 2.5 [1]. The operators read that across to the flight case: dig sites at the lunar south pole should be expected to compact progressively over a mission while dump sites become progressively looser.
Public domain (NASA / US government work).
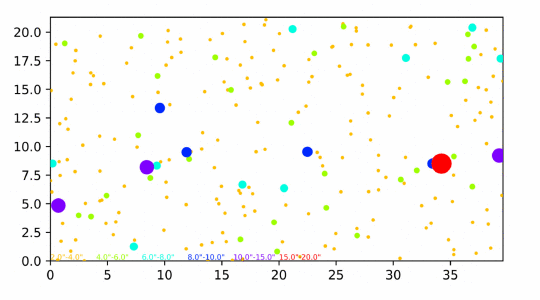
The rock field is generated rather than arranged by eye: rocks are binned into discrete size ranges and placed at random positions at an areal density taken from a power law fit to Surveyor VI block counts, using the number of rocks per square meter between size bounds as N = a(d_min^b - d_max^b)/100 [1]. Cintala and McBride fitted power laws of the form N = a d^b to fragment size distributions measured from Surveyor surface photography [3].
| Surveyor VI power law fit | Value |
|---|---|
| Rock size range placed | 4 to 20 cm |
| a | 0.154, errors +0.088/-0.019 |
| b | -2.286, standard error 0.094 |
| Correlation coefficient | 0.983 |
Source: [3].
Mock lander
Section titled “Mock lander”| Parameter | Value |
|---|---|
| Working volume | 2.75 m diameter, 1.2 m tall, standing in the practice area |
| Test article limits | Docking approach only; no published mass limit |
| Illumination | White top deck, gold metallic sides, silver metallic legs, lit by the stadium fixtures |
| Instrumentation | 3 FLIR Blackfly S BFS-GE-88S6-M cameras, Kowa LM6JC 6 mm lenses; 16 AprilTag 36h11 fiducials |
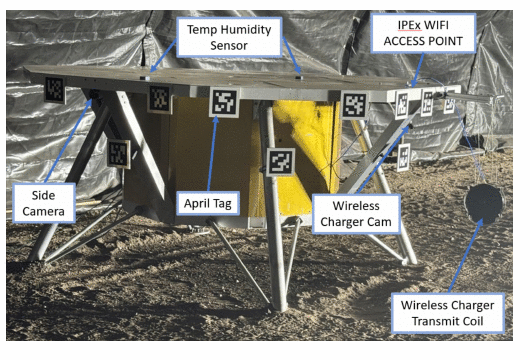
The lander is the navigation target and the site’s service node, 2.75 m in diameter and 1.2 m tall, finished with a white top deck, gold metallic sides and silver metallic legs, and carrying 16 AprilTag 36h11 fiducials, 15.24 x 15.24 cm overall with a 12.1 x 12.1 cm black-to-black edge, mounted along the top perimeter and at the mid-span of the legs and angle braces, and painted onto polycarbonate sheet, flat white vinyl for the light field and Musou black acrylic, quoted at up to 99.4 percent absorption, for the dark field, which holds tag contrast while suppressing specular return from the solar simulator [1].
Public domain (NASA / US government work).
As the service node it carries a network switch onto the flight control room network, the article’s Wi-Fi access point, the temperature and humidity sensors, three fixed cameras, and a wireless charger transmit coil suspended on cables and offset from the front face so that an off-nominal docking approach cannot damage the coil or the article.
Instrumentation
Section titled “Instrumentation”Pose ground truth comes from 36 OptiTrack Slim x13 cameras around the perimeter of the practice area, tracking a beacon on the article [1]. An independent characterization of the same class of hardware, a 16-camera Primex41 array at NASA Glenn’s lunar soil bins, checked the system’s self-reported mean wand error of 0.17 mm against a linear stage and found it honest as an aggregate figure, but found error in specific regions of the working volume running higher where test hardware occludes cameras [10]; the site’s own published pose accuracy is not broken out by region. The pose is published on a ROS topic, so it is logged alongside the article’s own telemetry in the same time series database and is available to the out-of-simulation operators live.
Situational coverage is four Axis cameras: two Q6128-E pan-tilt-zoom units on the ceiling in the front corners, a third Q6128-E on a movable ground tripod, and an M3058-PLVE fixed fisheye at the ceiling center giving a whole-field overview. Access to these views is restricted to the simulation coordinator, so that the in-simulation operators see only what a flight downlink would carry.
The lander’s three FLIR Blackfly S BFS-GE-88S6-M cameras are fixed focus and fixed focal length with Kowa LM6JC 6 mm lenses: two side-facing units look at the dig and dump areas and one front-facing unit is angled down for docking verification, and during the TRL 5 run only the docking camera was used, on the assumption that the side cameras might not be available for a full flight mission [1].
Soil state is measured with a Geotester pocket penetrometer, run as a survey after a campaign rather than continuously, comparing undisturbed ground, trafficked ground, the dig site and the dump site.
What it does not reproduce
Section titled “What it does not reproduce”Gravity and granular behavior. The site runs at Earth gravity (see Laboratory data above). The operators state directly that replicating the granular properties of the lunar south pole remains a challenge under that gravity. Bearing capacity, sinkage and excavation reaction forces measured here are not transferable to lunar conditions without a separate model.
Regolith. The bed is local Florida soil. Lunar simulants such as LHS-1 were considered and rejected because of the logistical, financial and safety burden of handling simulant in a facility of this size. The stated compensation is that Florida soil still provides a challenging traverse and excavation medium for autonomy work, not that it reproduces regolith. Simulant-based mobility and excavation testing for the same program is run separately in the KSC Regolith Test Bed with BP-1 [5].
Optical properties. Measured site albedo (see Laboratory data above) runs well above published lunar surface albedo. The site is brighter and less absorbing than the terrain it stands in for, which biases exposure and contrast in the direction of an easier problem.
Illumination uniformity and collimation. Six point sources at finite distance do not approximate a collimated beam from an effectively infinite source; measured illuminance falls by two orders of magnitude across the practice area (see the illuminance table above). The operators describe this non-uniformity as a challenge for consistent imaging but reuse it deliberately, as a range of conditions for testing adaptive exposure as the article crosses from the bright to the dim end. Solar elevation and azimuth are fixed by the physical fixture placement; varying them is listed as future work.
Blackout. The panel weave blocks most but not all light, and the panels drape short of the floor, leaving the enclosure short of a true lunar sky (see the blackout table above).
Craters. No craters are present. The paper states that their inclusion is an ongoing effort and lists more diverse terrain features, craters of various sizes among them, as future work.
Rock statistics. The Surveyor VI fit was derived from fragments typically below 1 m seen in surface photography [3]. Cintala and McBride found that extrapolating those fits to blocks above 2.5 m overestimates the areal density measured from orbital photography at every site but Surveyor III, and that the cumulative block population is therefore probably nonlinear with different slopes over different size intervals [3]. The same work found the areal density of blocks within 1.1 crater radii to be about a factor of ten higher than the intercrater density at all three mare sites, a clustering the site’s uniform random placement does not reproduce. The paper also notes that the Surveyor VII highlands site near Tycho carried a far higher large-block density than the mare sites, and that a polar site may differ again from the Surveyor VI model adopted [1][3].
Dust. Electrostatic lofting, adhesion to lenses and radiators, and abrasion are named as lunar south pole problems in the same paper but are outside what the site addresses; the stated focus is the visual effects seen by camera-based systems. Thermal vacuum and dust exposure for the same program’s cameras were run in the ASSIST chamber at the GMRO lab instead [4], a dirty thermal vacuum chamber run from 760 torr down to 3.5e-6 torr with a xenon arc solar simulator and a regolith-bed build plate for combined excavation and additive construction testing under simulated lunar or Martian pressure [9]. Airborne dust itself is instrumented separately again, in the GMRO lab’s regolith bins rather than at either the autonomy site or ASSIST: a laser and camera extinction sensor there found that spot measurements of dust density collapse toward zero above roughly 1e10 particles per cubic meter, so side-scatter measurement is needed once a cloud gets that dense, and that dust raised by a nine-laser test array took about an hour to clear from a test bed [11].
Campaigns run there
Section titled “Campaigns run there”IPEx TRL 5 mission demonstration, August 2024. Five days of continuous operation beginning 25 August 2024, run as a mock mission against the IPEx concept of operations, which requires roughly 5.7 million actuator input revolutions and drives the actuator qualification program run in parallel at the GMRO lab [4]. The article was the alpha configuration of the TRL 5 hardware with larger external battery packs and surrogate avionics based on the final flight computer; all localization and autonomy software ran onboard. The site was configured with a statistically generated rock field unknown to the operators, low solar angle stadium lighting, reduced data transmission and a simulated 14 second round-trip delay standing in for a Commercial Lunar Payload Services lander relay, with ground control sitting in the IPEx flight control room 183 m from the site [1], with four telemetry displays on the flight control computer for in-simulation work and a separate console for the simulation coordinator carrying real-time, undelayed telemetry and imagery. Four shifts of four crew each ran the mission: primary operator, secondary operator, telemetry desk officer, and simulation coordinator, the last holding the only access to the situational cameras and performing out-of-simulation actions such as battery changes.
Measured result: continuous robot operation that, after subtracting thermal resets and wireless charging events, corresponded to a mock mission of several days of simulated time. Each repetition ran three drives, then excavation and unloading, then three more drives. The demonstration closed with operational margin in hand, and no equipment in the site lost power over the period.
| Campaign result | Value |
|---|---|
| Continuous robot operation | 77 h 46 min |
| Simulated mission time (after subtracting resets and charging) | 205 h 18 min, about 8 days |
| Distance traversed | 58.1 km across 334 mission repetitions |
| Maximum sustained drive speed | 40 cm/s |
| Docking and recharge cycles | 35, averaging 10 repetitions per battery charge |
| Drive length per leg | About 100 m, averaging nine minutes |
| Operational margin at close | 59 h |
Two datasets were released from the campaign. The instance segmentation set carries manually annotated instances across four classes: lander, rock, fiducial and fiducial inverse, with both bounding boxes and pixel-wise masks. Annotation was done in CVAT with Segment Anything as a serverless assist, with manual correction needed on heavily shadowed images. The imagery was collected not by IPEx but by a Clearpath Robotics Husky surrogate carrying prototype IPEx FLIR Blackfly S cameras with 6 mm Kowa lenses, driven in arcing and figure-of-eight patterns near the mock lander [1].
| Instance segmentation dataset | Value |
|---|---|
| Images | 2,343 |
| Annotated instances | 10,505 |
| Mean mask area, lander | 330,010 px |
| Mean mask area, rock | 35,358 px |
| Mean mask area, fiducial | 2,880 px |
| Mean mask area, inverse fiducial | 2,361 px |
The photogrammetry set was taken during the mapping phase of the mock mission from four cameras on synchronized intervals of linear driving. Stereo pairs were set to hyperfocal distance; the side cameras were manually focused to hold the lander at a fixed driving radius and ran a custom auto-exposure routine that exposed for the lander fiducials during arcing drives. The set has been processed into ground-based maps with COLMAP structure from motion and with neural radiance fields.
| Photogrammetry dataset | Value |
|---|---|
| Images | 1,514 |
| Camera interval | Every 0.5 m of linear driving |
| Front and rear stereo pairs | IDS GV-51F1SE, Sony IMX547 sensor, binned to 1230 x 1028 |
| Side cameras | Same sensor, binned to 2460 x 2056, monochrome |
| Side camera driving radius | 7 m |
Autonomous excavation algorithm development, 2022 onward. The autodig control work that the site’s excavation runs exercise was developed on the RASSOR 2 prototype in the GMRO lab regolith bin, not in the autonomy test site, because that bin holds BP-1 simulant [4]. RASSOR 2 is the counter-rotating bucket drum excavator IPEx descends from: two opposed drum pairs cancel the horizontal reaction force so the 66 kg vehicle can excavate without needing traction, at a design mass half that of its predecessor for double the payload capacity [7]. The force and torque a bucket drum of IPEx’s scale generates while cutting, which sizes the excavation rates the autonomy test site’s dig-and-dump cycle exercises, were measured separately on an instrumented gantry rather than at this site [8]. The autonomy test site is where the resulting stack is run end to end against a rock field and a lander, exercising the supervised autonomous navigation mode that the flight design assumes [4].
Wheel configuration testing, 2023 to 2024. Ten wheel configurations, drawn from 24 possible combinations of cleat shape and perforation, cleat spacing, and grouser shape, height and spacing, were driven on RASSOR 2.0 fitted with 30.5 cm IPEx-sized reconfigurable wheels as an IPEx surrogate in the KSC Regolith Test Bed, an 8 x 8 x 1.1 m bed holding 120 tons of BP-1 [5]. Tests covered circle driving, straight driving, a 20 degree prepared slope and drawbar pull, 83 tests in total, with slip computed from OptiTrack motion capture and power taken as summed motor current times pack voltage. Taller and squarer grousers slip less but draw more power, shorter and rounder grousers do the reverse, and solid versus perforated cleats made no discernible difference to either, so the lighter perforated cleats cost nothing; no single configuration won across all four test types, and the recommended baseline is a curved perforated cleat with short curved grousers [5]. This is the simulant-based counterpart to the autonomy site’s Florida soil traverses.
Navigation primitive development, 2022. The circular traverse pattern around the lander that the site’s layout is built to support was developed against dynamic movement primitives with an added obstacle avoidance term, modified to bound each obstacle’s influence by proximity rather than letting the sum of all obstacles push the trajectory outward, and evaluated first in the Simulated Excavation Environment for Lunar Operations, a Unity-based simulator with terrain deformation and modeled battery depletion, using a RASSOR 2.0 model in densely populated rock fields [6]. Across 10 rock distributions of 70 non-traversable rocks each at 0.15 rocks per square meter in a 22 x 22 m worksite, and a further 100 novel distributions, the modified method reached the goal with zero collisions in every run, against 426 collisions for the unmodified method and 425 for the original avoidance formulation, at a path-length cost of 44.11 plus or minus 0.65 m against a 43.45 m nominal circle [6]. The physical rock field in the test site is the corresponding hardware case.
References
- Cloud, J. M., Nick, A. J., Buckles, B. C., Dixon, K. L., Muller, T. J., Ortega, V. V., Smith, J. D., Clark, C. J., Dyas, J. E., Zhang, E. L., Leucht, K. W., Mueller, R. P. and Schuler, J. M. (2025). The IPEx Autonomy Test-Site: Terrestrial Testing of Autonomous Excavation in Lunar South Pole Conditions
. ASCE Earth and Space Conference, 20250000128. Source
BibTeX
@inproceedings{cloud2025ipex, title = {The IPEx Autonomy Test-Site: Terrestrial Testing of Autonomous Excavation in Lunar South Pole Conditions}, author = {Cloud, Joseph M. and Nick, Andrew J. and Buckles, Bradley C. and Dixon, Kyle L. and Muller, Thomas J. and Ortega, Victoria V. and Smith, Jonathan D. and Clark, Casey J. and Dyas, Jeffrey E. and Zhang, Elizabeth L. and Leucht, Kurt W. and Mueller, Robert P. and Schuler, Jason M.}, booktitle = {ASCE Earth and Space Conference}, number = {20250000128}, pages = {1-14}, institution = {NASA}, year = {2025}, doi = {10.1109/aero63441.2025.11068688}, abstract = {NASA's Artemis program aims to send humans to the lunar south pole (LSP), requiring in-situ resource utilization (ISRU) technologies like the ISRU Pilot Excavator (IPEx) to perform site preparation and resource extraction. The LSP is a uniquely challenging environment, characterized by low solar angles and long shadows that disrupt vision-based autonomy. To approximate these conditions, we developed the IPEx autonomy test-site, a 21.3×33.5 m enclosed area for testing excavation technologies under simulated LSP conditions. The test-site is equipped with granular material, scattered rocks, and a full-scale lander model. Strategically placed high-power lights replicate the low solar angles, while a motion capture system offers ground truth robot poses. Additional site awareness cameras provide complete coverage of the test area for monitoring. The test-site has been utilized to evaluate performance of both autonomous navigation and excavation tasks. Finally, we discuss initial results obtained from test runs, calculations compared against a digital simulation, features of the terrain that mimic the visual properties of lunar regolith, and challenges observed.} } - NASA Kennedy Space Center. (2025). Surface Autonomy Test Site. public.ksc.nasa.gov/partnerships/surface-autonomy-test-site
BibTeX
@misc{ksc2025surface, title = {Surface Autonomy Test Site}, author = {{NASA Kennedy Space Center}}, organization = {public.ksc.nasa.gov}, year = {2025}, url = {https://public.ksc.nasa.gov/partnerships/surface-autonomy-test-site/} } - Cintala, M. J. and Mcbride, K. M. (1995). Block distributions on the lunar surface: A comparison between measurements obtained from surface and orbital photography
. NASA, NASA-TM-104804. Source
BibTeX
@techreport{cintala1995block, title = {Block distributions on the lunar surface: A comparison between measurements obtained from surface and orbital photography}, author = {Cintala, Mark J. and Mcbride, Kathleen M.}, number = {NASA-TM-104804}, institution = {NASA}, year = {1995}, url = {https://ntrs.nasa.gov/citations/19960011631}, abstract = {Among the hazards that must be negotiated by lunar-landing spacecraft are blocks on the surface of the Moon. Unfortunately, few data exist that can be used to evaluate the threat posed by such blocks to landing spacecraft. Perhaps the best information is that obtained from Surveyor photographs, but those data do not extend to the dimensions of the large blocks that would pose the greatest hazards. Block distributions in the vicinities of the Surveyor 1, 3, 6, and 7 sites have been determined from Lunar Orbiter photography and are presented here. Only large (i.e., greater than or equal to 2.5 m) blocks are measurable in these pictures, resulting in a size gap between the Surveyor and Lunar Orbiter distributions. Nevertheless, the orbital data are self-consistent, a claim supported by the similarity in behavior between the subsets of data from the Surveyor 1, 3, and 6 sites and by the good agreement in position (if not slopes) between the data obtained from the Surveyor 3 photography and those derived from the Lunar Orbiter photographs. Confidence in the results is also justified by the well-behaved distribution of large blocks at the surveyor site. Comparisons between the Surveyor distributions and those derived from the orbital photography permit these observations: (1) in all cases but that for Surveyor 3, the density of large blocks is overestimated by extrapolation of the Surveyor-derived trends; (2) the slopes of the Surveyor-derived distributions are consistently lower than those determined for the large blocks; and (3) these apparent disagreements could be mitigated if the overall shapes of the cumulative lunar block populations were nonlinear, allowing for different slopes over different size intervals. The relatively large gaps between the Surveyor-derived and Orbiter-derived data sets, however, do not permit a determination of those shapes.} } - Schuler, J. M., Smith, J. D., Nick, A. J., Buckles, B. C., Dyas, J. E., Ortega, V. V., Cloud, J. M., Dokos, A. G., Zhang, E. L., Wang, J. J., Baron, M. A., Muller, T. J., Clark, C. J. and Howe, M. W. (2024). ISRU Pilot Excavator (IPEx) Technology Readiness Level 5 Design Overview
. AIAA AVIATION Forum and ASCEND, 20240008162. Source
BibTeX
@inproceedings{schuler2024isru, title = {ISRU Pilot Excavator (IPEx) Technology Readiness Level 5 Design Overview}, author = {Schuler, Jason M. and Smith, Jonathan D. and Nick, Andrew J. and Buckles, Bradley C. and Dyas, Jeffrey E. and Ortega, Victoria V. and Cloud, Joseph M. and Dokos, Adam G. and Zhang, Elizabeth L. and Wang, Jerry J. and Baron, Michael A. and Muller, Thomas J. and Clark, Casey J. and Howe, Musashi W.}, booktitle = {AIAA AVIATION Forum and ASCEND}, number = {20240008162}, institution = {NASA}, year = {2024}, doi = {10.2514/6.2024-4890}, abstract = {This paper details the mechanical and mechatronic design of the Technology Readiness Level (TRL)-5 In-Situ Resource Utilization (ISRU) Pilot Excavator (IPEx). IPEx is a robotic excavator designed for a technology demonstration of regolith mining in the lunar south pole region. The novel design uses pairs of counter-acting excavation tools called bucket drums, that dig at the same time in opposing directions to reduce the reaction force needed, thereby enabling mining with a small, low-mass, robotic system. IPEx builds on the prior work of the Regolith Advanced Surface Systems Operations Robot (RASSOR), which is the TRL-4 implementation of this concept. The TRL-5 IPEx subsystems that are discussed in this paper include: Regolith Delivery Subsystem (RDS), Mobility Subsystem (MS), Cameras and Dust Mitigation Subsystem (CDMS), and Thermal Control Subsystem (TCS). Each subsystem is described in detail with rationale for design selections. Dust tolerance is a key feature for IPEx, and this paper details a thermal control system with an actuated radiator cover and phase change material as well as camera modules with removable electrodynamic dust shields (EDS). Additional components such as actuators, wheels, and bucket drums are discussed in detail. Due to their complexity, the avionics and software subsystems will be discussed in a separate publication.} } - Zhang, L., Schuler, J., Dokos, A., Xu, Y., Bell, E. and Muller, T. (2024). ISRU Pilot Excavator Wheel Testing in Lunar Regolith Simulant
. Earth and Space, 20240001016. Source
BibTeX
@inproceedings{zhang2024isru, title = {ISRU Pilot Excavator Wheel Testing in Lunar Regolith Simulant}, author = {Zhang, Liz and Schuler, Jason and Dokos, Adam and Xu, Yinan and Bell, Evan and Muller, Thomas}, booktitle = {Earth and Space}, number = {20240001016}, pages = {173-187}, institution = {NASA}, year = {2024}, doi = {10.1061/9780784485736.016}, abstract = {The ISRU Pilot Excavator (IPEx), is a robotic excavator funded by NASA’s Space Technology Mission Directorate (STMD). The Concept of Operations for IPEx involves the robot driving on the lunar surface up to 70 km at a speed of up to 30 cm/s. As such, it is critical to the mission’s success to optimize the design of the wheels for performance in lunar conditions, specifically in lunar regolith. To achieve this, an array of tests was completed to observe the effects of various wheel design choices on the driving performance of the wheels in lunar regolith simulant. In order to facilitate testing, we designed a 12 in. dia. configurable wheel to allow for interchangeability between various wheel formations. Two types of wheel parts were designed to be swapped: cleats, which form the tread of the wheel; and grousers, which protrude from the treads. The test variables that we considered were as follows: square versus round wheel shape, solid versus perforated cleats, cleat spacing, grouser height, and grouser spacing. By combining different settings of each of these test variables, 10 discrete wheel designs were created and tested. The configurable test wheels were mounted on the Regolith Advanced Surface Systems Operations Robot (RASSOR) developed at NASA’s Kennedy Space Center. In our experiments, the robot was driven at a controlled speed across a prepared surface of BP-1 lunar regolith simulant. Four types of tests were conducted: circle driving, straight driving, slope driving, and drawbar pull. The driving tests were chosen to mimic a variety of conditions in which IPEx may be expected to operate, and the drawbar pull test was chosen to provide a standard of comparison with existing wheel design literature. The circle and straight driving tests were each performed at different levels: for the circle driving test, the robot was driven at a constant linear speed and three different angular speeds, while for the straight driving test, the robot was driven at three different linear speeds. The data collected from these tests included the power usage from each of the wheels, measurements of the tread patterns left in the regolith surface, and the amount of slip the wheels experienced, which was calculated using data from an OptiTrack motion capture system. From the results of these experiments, we found that certain test variables were more significant than others in determining performance for each type of test, and no single wheel design clearly outperformed the others in all areas. The details of our findings will be discussed further in this paper. These data will be utilized to inform the design of the wheels for IPEx and can provide a basis for the design of wheels for future lunar terrain vehicles.} } - Cloud, J. M., Tram, M. Q., Beksi, W. J. and Dupuis, M. A. (2023). Lunar Excavator Mission Operations using Dynamic Movement Primitives
. IEEE/RSJ International Conference on Intelligent Robots and Systems, 20220014197. Source
BibTeX
@inproceedings{cloud2023lunar, title = {Lunar Excavator Mission Operations using Dynamic Movement Primitives}, author = {Cloud, Joseph M. and Tram, Minh Q. and Beksi, William J. and Dupuis, Michael A.}, booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems}, number = {20220014197}, pages = {10708-10715}, institution = {NASA}, year = {2023}, doi = {10.1109/iros55552.2023.10342005}, abstract = {To support sustainable infrastructure on the Moon, NASA must leverage robots to extract lunar resources for in-situ processing and construction. As part of this effort, NASA is launching the in-situ resource utilization (ISRU) Pilot Excavator later this decade to validate a robotic regolith excavator based on the Regolith Advanced Surface Systems Operations Robot (RASSOR). RASSOR is designed to extract and transport regolith to meet the needs of ISRU architectures. During its mission, Pilot Excavator will be tasked with driving in test patterns to demonstrate the operational concept. One possible test pattern is a circular trajectory around the lander while avoiding surface hazards such as lunar rocks. To this end, we utilize dynamic movement primitives to represent navigation sequences as primitive trajectories. We introduce a novel obstacle avoidance parameter, which is configured to avoid rocks throughout testing exercises. We demonstrate the effectiveness our method in a newly developed simulation tool called the Simulated Excavation Environment for Lunar Operations (SEELO) using models based on the NASA RASSOR 2.0 excavator. Our results show that the robot is able to safety and robustly navigate the lunar surface with densely populated rock obstacles while retaining the desired circle pattern behavior.} } - Mueller, R. P., Smith, J. D., Schuler, J. M., Nick, A. J., Gelino, N. J., Leucht, K. W., Townsend, I. I. and Dokos, A. G. (2016). Design of an Excavation Robot: Regolith Advanced Surface Systems Operations Robot (RASSOR) 2.0
. Earth and Space, 20210011366. Source
BibTeX
@inproceedings{mueller2016design, title = {Design of an Excavation Robot: Regolith Advanced Surface Systems Operations Robot (RASSOR) 2.0}, author = {Mueller, Robert P. and Smith, Jonathan D. and Schuler, Jason M. and Nick, Andrew J. and Gelino, Nathan J. and Leucht, Kurt W. and Townsend, Ivan I. and Dokos, Adam G.}, booktitle = {Earth and Space}, number = {20210011366}, pages = {163-174}, institution = {NASA}, year = {2016}, doi = {10.1061/9780784479971.018}, abstract = {To continue on a sustainable and flexible path, NASA needs to address the challenge of collecting and moving large amounts of regolith at the destination. Acquiring the water resources on Mars will require mining significant quantities of regolith, and this is not possible with the state-of-the-art low mass excavation systems. Low gravity environments (Mars = 3/8G) and launch mass restrictions limit the traction and the resulting reaction force of the vehicle, making current terrestrial techniques impractical. This project addressed this challenge by developing a completely new technology that can mine large quantities of regolith on Mars. Recent measurements by the “Curiosity” rover on Mars have found that the regolith contains ~2% water by weight globally, ~4% in Jezero Crater (Human Architecture Team’s reference landing site), and much more at the poles. RASSOR 2.0 is a planetary excavator, which has a mass of 66 kg, with a 0.38 kg vehicle mass per kilogram, per hour of excavation rate and power usage of 4 W per kg of regolith excavation rate. A single RASSOR 2.0 can excavate a minimum of 2.7 metric tons of regolith per day. This is accomplished by using counteracting excavation forces on two opposing digging implements called bucket drums and an autonomous mining control system. This work has addressed several major research areas outlined in the NASA Technology Area (TA) 04 Robotics and Autonomous Systems and TA 07 Human Destination Systems roadmaps. This project started at Technology Readiness Level (TRL) 4 as a low fidelity “proof of concept” prototype which has successfully demonstrated basic regolith simulant excavation functionality in a lab-scale gravity off load test. The foundational technology described here was awarded US patent number: US 9027265 for a “Zero horizontal reaction force excavator” on May 12, 2015.} } - Schuler, J., Nick, A., Leucht, K., Langton, A. and Smith, D. (2022). ISRU Pilot Excavator: Bucket Drum Scaling Experimental Results
. Earth and Space, 20210025846. Source
BibTeX
@inproceedings{schuler2022isru, title = {ISRU Pilot Excavator: Bucket Drum Scaling Experimental Results}, author = {Schuler, Jason and Nick, Andrew and Leucht, Kurt and Langton, Austin and Smith, Drew}, booktitle = {Earth and Space}, number = {20210025846}, pages = {394-407}, institution = {NASA}, year = {2022}, doi = {10.1061/9780784484470.037}, abstract = {NASA’s Space Technology Mission Directorate (STMD) is funding the development of a robotic excavator called the “ISRU Pilot Excavator” (IPEx) which will be a technology demonstration of excavating and transporting 10 metric tons of lunar regolith on the surface of the Moon with a 30 kg-class robotic excavator. IPEx will be the next generation of robotic excavators to use bucket drums as excavation tools. This is an evolution of the regolith advanced surface systems operations robot (RASSOR) developed at NASA’s Kennedy Space Center (KSC). Bucket drums are hollow cylinders with regularly spaced scoops around the perimeter. The drums rotate in one direction to collect regolith with the scoops. The regolith slides down an internal baffling system inside the drum which prevents the regolith from falling back out of the scoops. The captured regolith can then be transported while held in the drum and then deposited by rotating the drum in the opposite direction allowing the regolith to slide back down the baffling and out of the excavation scoops. Bucket drums were developed by Lockheed Martin in 2008 and used on multiple robotic excavator prototypes ever since. However, the forces on a bucket drum and considerations for scaling have not been measured in detail. Bucket drums are challenging to model using classical blade\bucket equations because of their unique geometry. Therefore, this experiment was performed to measure the forces on three bucket drums of the same geometry at different scales. Small: 9.4” (239 mm) dia. × 8.1” (206 mm) width, medium: 11.6” (294 mm) dia. × 10” (254 mm) width, and large: 17” (432 mm) dia. × 14.1” (358 mm) width. The test stand consisted of an actuated gantry with controlled motion in the vertical (Z) and horizontal (X) axes and a single rotation axis (R). The bucket drums were individually mounted to the rotary axis of the test stand and translated across a prepared bed of Black Point 1 (BP-1) lunar regolith simulant at a specified linear speed and cutting depth. The test stand was outfitted with a torque sensor in line with the rotation of the drum (R) and a 3 axis (X, Y, and Z) load cell. In addition to the three sizes of bucket drums the linear excavation speed and cutting depth were test variables. The results of these experiments show the relationship between the three scales of bucket drums for factors such as: excavation force, torque due to regolith rotation inside the drum, excavation energy, time to fill, etc. and will be discussed in detail in this paper. This fundamental data will be used in the design of IPEx and can inform the design of future bucket drum excavators.} } - NASA Kennedy Space Center. (2025). Advanced Regolith Ground Operations (ARGO) Test Bed and the ASSIST Chamber. public.ksc.nasa.gov/partnerships/advanced-regolith-ground-operations-...
BibTeX
@misc{ksc2025advanced, title = {Advanced Regolith Ground Operations (ARGO) Test Bed and the ASSIST Chamber}, author = {{NASA Kennedy Space Center}}, organization = {public.ksc.nasa.gov}, year = {2025}, url = {https://public.ksc.nasa.gov/partnerships/advanced-regolith-ground-operations-argo-test-bed-a-robotic-excavation-and-construction-test-facility-with-simulated-lunar-environments/} } - Schepelmann, A. and Gerdts, S. (2022). Characterization of Infrared Optical Motion Tracking System in NASA's Simulated Lunar Operations (SLOPE) Laboratory
. NASA, NASA/TM-20220005304. Source
BibTeX
@techreport{schepelmann2022characterization, title = {Characterization of Infrared Optical Motion Tracking System in NASA's Simulated Lunar Operations (SLOPE) Laboratory}, author = {Schepelmann, Alexander and Gerdts, Stephen}, number = {NASA/TM-20220005304}, institution = {NASA}, year = {2022}, url = {https://ntrs.nasa.gov/citations/20220005304}, abstract = {This work characterizes the accuracy of a 16 camera OptiTrack motion tracking system installed in NASA Glenn Research Center's Simulated Lunar Operations (SLOPE) laboratory. The position of a rigid body mounted on a motorized linear stage is compared to its position reported by the motion tracking system as it travels through the facility's 777m$^3$ capture volume of interest. Experiments show that the mean error reported by the motion tracking system for the aggregate capture volume is in-line with independent measurements collected using the motion stage. Error within regions of the capture volume exceed the mean error reported by the motion tracking system, likely due to occlusion, and suggests that additional cameras should be used to increase measurement accuracy in these regions. Overall, results show that error values reported by the motion tracking system are representative of the measurement error in a collected data set and validates the system's use for characterizing the mobility and tractive performance of robots, rovers, and other vehicles for planetary exploration.} } - Lane, J. E., Mantovani, J., Mueller, R., Nugent, M., Nick, A., Schuler, J. and Townsend, I. I. (2016). Optical Extinction Measurements of Dust Density in the GMRO Regolith Test Bin
. Earth and Space, 20160005055. Source
BibTeX
@inproceedings{lane2016optical,
  title = {Optical Extinction Measurements of Dust Density in the GMRO Regolith Test Bin},
  author = {Lane, John E. and Mantovani, J. and Mueller, R. and Nugent, M. and Nick, A. and Schuler, J. and Townsend, Ivan I.},
  booktitle = {Earth and Space},
  number = {20160005055},
  pages = {36-47},
  institution = {NASA},
  year = {2016},
  doi = {10.1061/9780784479971.005},
  abstract = {A regolith simulant test bin was constructed and completed in the Granular Mechanics and Regolith Operations (GMRO) Lab in 2013. This planetary regolith test bed (PRTB) is a 64 m2 × 1 m deep test bin housed in a climate-controlled facility and contains 120 MT of lunar-regolith simulant, called Black Point-1 or BP-1, from Black Point, AZ. One of the current uses of the test bin is to study the effects of difficult lighting and dust conditions on telerobotic perception systems to better assess and refine regolith operations for asteroid, Mars, and polar lunar missions. Low illumination and low angle of incidence lighting pose significant problems to computer vision and human perception. Levitated dust on asteroids interferes with imaging and degrades depth perception. Dust storms on Mars pose a significant problem. Due to these factors, the likely performance of telerobotics is poorly understood for future missions. Current space telerobotic systems are only operated in bright lighting and dust-free conditions. This technology development testing will identify: (1) the impact of degraded lighting and environmental dust on computer vision and operator perception, (2) potential methods and procedures for mitigating these impacts, (3) requirements for telerobotic perception systems for asteroid capture, Mars dust storms, and lunar regolith ISRU missions.}
}