DLR Institute of Space Systems Landing and Mobility Test Facility
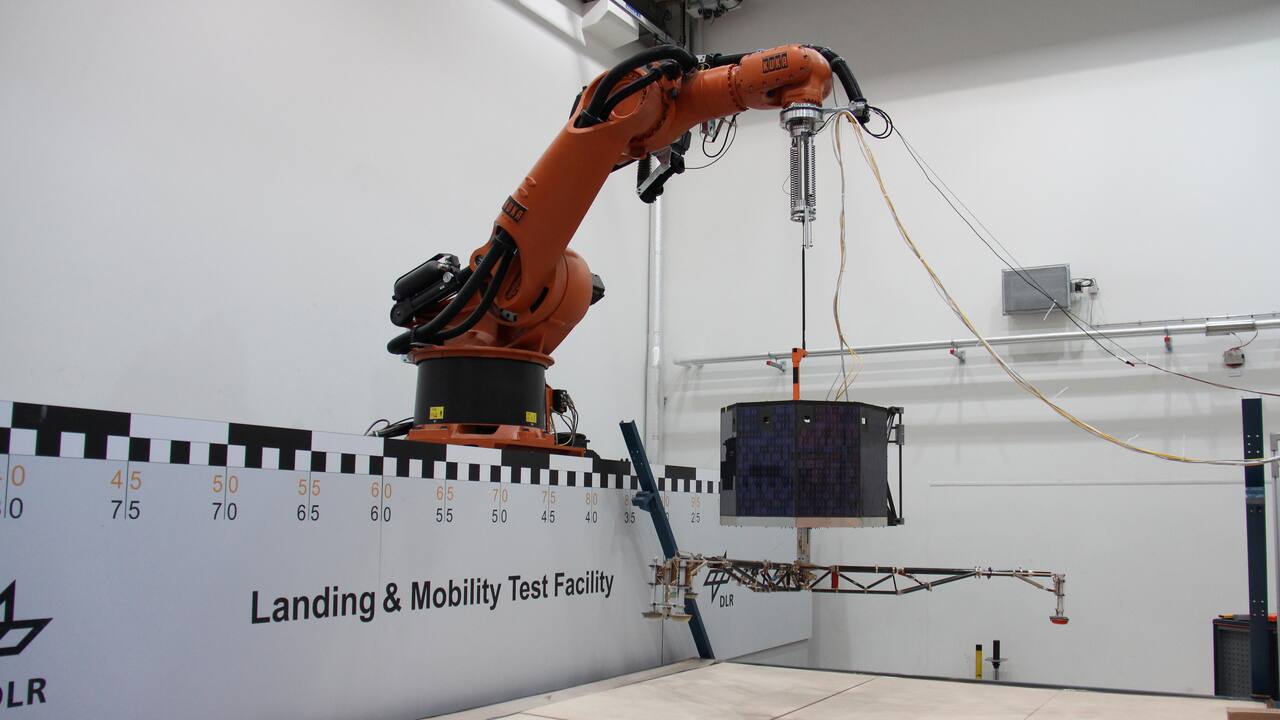
DLR. Source: [2]. CC BY 3.0.
LAMA is a landing dynamics laboratory, not a drop tower. A six-axis industrial robot on a 12 m linear rail carries the test article through a commanded touchdown trajectory while a suspension device between the robot flange and the article removes most of its weight, so a lander designed for 1.6 m/s2 or for a comet can be dropped onto real soil at Earth gravity [1][2]. The soil is the point: the operators state that the facility exists because footpad and landing gear behavior on granular media cannot be obtained from a pendulum or a tilted plane, which “does not allow tests on granular media”.
It is run by the Institute of Space Systems in Bremen, in the Landing and Exploration Technologies department, which is a different DLR institute some 700 km from the Oberpfaffenhofen terramechanics laboratories, TROLL and the Planetary Exploration Laboratory [1]. The two rigs in the hall correspond to the two halves of the name: a landing rig that flies an article into the soil, and a mobility rig that drags a footpad or a wheel horizontally through it [1][2].
Laboratory data
Section titled “Laboratory data”| Parameter | Value |
|---|---|
| Operator | DLR Institute of Space Systems, Landing and Exploration Technologies |
| Location | Robert-Hooke-Strasse 7, 28359 Bremen, Germany |
| Commissioned | In service by 2010; first published campaign 2011 |
| Type | Robotic landing dynamics rig with active weight offloading, over a soil bin |
| Floor area | Soil bed 10 x 4 m, in a dedicated test cell. Cell area not published |
| Capabilities | Landing test rig, mobility rig |
| Simulant or terrain | WF34 quartz sand; MSS-D lunar simulant; concrete |
| Instrumentation | ATI Theta force-torque transducer in the robot flange |
| Ground truth | Robot hand pose, 0.15 mm, every 12 ms; video to 600 fps |
| Fidelity limits | Offload interference remains; soil preparation dominates error |
| Access | Institute-run. No external user route published |
| Cited by | philae [2]; mmx-rover [3] |
Capabilities
Section titled “Capabilities”Landing test rig
Section titled “Landing test rig”| Parameter | Value |
|---|---|
| Working volume | Drops onto a 4 x 3 m part of the 10 x 4 m bed; 12 m rail travel |
| Test article limits | Robot static load 500 kg; drop object 125 to 300 kg |
| Vacuum | Not applicable. No vacuum capability described |
| Temperature | Not applicable. Not a thermal facility |
| Illumination | Not applicable. No solar simulator described |
| Simulant or terrain | WF34 quartz sand, concrete, wood, oiled steel |
| Slope | Not set as terrain. Impact angle from the velocity ratio |
| Gravity offload | Active, spring suspension on the flange; accuracy not published |
| Instrumentation | ATI Theta force-torque; Megatron RC20 stroke transducer, 1 kHz |
The robot is the test machine. A KUKA KR500 on a KL1500-2 linear axis gives 12 m of lateral travel over the bed, and flies the article along a commanded trajectory whose horizontal and vertical velocity components set the impact angle; vertical velocity comes from the release height, and a pneumatic parallel gripper on the flange releases the dummy mass at a preprogrammed instant once the robot has reached a horizontal velocity of up to 1 m/s [1]. Bed depth is not published. The facility is described as five elements: the robot, the rail track, the suspension device, the controller and the soil bin, in a dedicated test cell. Of the drop object mass, the operators note that “300 kg is also the maximum payload mass of the test object, caused by the configuration” [2].
The suspension device between the flange and the article is what makes a 1 g facility useful for a low-gravity landing; the chain from the flange down is an upper plate on the robot’s force-torque sensor, linear guide pillars constraining motion to the gravity axis, tension springs sized to the article’s mass, a movable lower plate on slide bearings, a piezoelectric brake, a carbon fiber beam stiff along its length and compliant in bending, and a cardanic joint whose center is trimmed to coincide with the article’s center of gravity [2]. Rotational freedom is about 30 degrees about x and y, reduced to about 17 degrees about y by the hood structure of the Philae model.
Two control modes exist. In the simpler one the robot flies a preprogrammed trajectory. In the sensor-driven mode the force-torque transducer in the hand closes a loop whose objective is to “maintain a constant weight load in the vertical direction and zero lateral forces in the robot hand”, which is how a comet-gravity or lunar-gravity landing is held through a touchdown that involves sliding and rebound [2][4].
Mobility rig
Section titled “Mobility rig”| Parameter | Value |
|---|---|
| Working volume | Drag container 3.2 x 1.2 m, set on top of the large bed |
| Test article limits | Footpad or leg on the flange; robot static load 500 kg |
| Simulant or terrain | MSS-D fine lunar simulant, used only here; WF34 |
| Slope | Footpad hinge tilts to 30 degrees, locking in 10 degree steps |
| Instrumentation | Instrumented footpad: 3-axis force, accelerometer, potentiometer |
Source: [1].
The mobility half of the facility pulls the article horizontally through the soil rather than dropping it onto it. In drag mode the leg is attached to the flange and pulled through the bin either at constant penetration depth with variable force, or at constant force with variable depth held by the robot controller, over a motion composed of a 1 m acceleration phase, a 1.5 m constant speed phase and a 0.5 m deceleration phase [1]. It uses its own smaller container placed on top of the large bed, which is also the only place the fine MSS-D simulant is used. Drag runs are noisier than drops, as the repeatability figures in the soil section below show.
The drag rig measures a footpad or a leg being pulled through soil at a controlled depth and force, which is the small-scale, single-body version of what a rover measures across a whole traverse. The only real-vehicle trafficability record at this scale is the Lunar Roving Vehicle’s: 2 to 3 percent wheel slip at a 6 to 7 km/hr cruise speed, over terrain up to 19 to 23 degrees, at an energy cost of 35 to 56 watt-hours per kilometer of which only about 15 percent went into the soil and the terrain rather than the vehicle itself [7]. LAMA has no rolling-wheel test mode and produces no traverse-scale number to set against that figure; its drag rig is a single instrumented foot or leg, not a wheel, and it runs over a few meters rather than kilometers.
Instrumentation
Section titled “Instrumentation”Measurement is split between the article, the robot and the room. The article carries accelerometers, potentiometers and force sensors at 1 kHz; the robot contributes hand pose, orientation, forces and torques from the control bus at 12 ms intervals with 0.15 mm position accuracy; and external video runs to 600 frames per second [1][2]. All three streams go to one central data acquisition system so that they share a time base.
The named sensor set is an ATI Theta three-axis force-torque transducer in the robot hand flange, a Megatron RC20 linear transducer on the suspension stroke at 1 kHz, an iMAR iVRU-BB-M inertial measurement unit at 100 Hz, and Kistler 8792A25 and Bruel and Kjaer DeltaTron 4506 accelerometers at 1 kHz, alongside landing gear housekeeping at 1 kHz [1][2]. The Philae specimen carried the flight landing gear housekeeping signals, gear stroke, tilt angle between gear and body, braking currents and touchdown signals, next to a flywheel generating the same angular momentum as the flight unit and ballast trimmed to the flight model mass, center of mass and moments of inertia [2].
The instrumented footpad built for the 2011 campaign is the clearest example of the design constraint the facility imposes: a three-axis accelerometer, a hinge-axis linear potentiometer and a three-axis force sensor, all sealed inside a plastic boot because the sensor is going into the sand [1].
Video is used as an independent check rather than as illustration. In the Philae campaign it established foot contact times to 83 ms and gave a measurement of hood tilt independent of the potentiometer, which is how the tilt limiter’s real performance was found [1].
Soil selection is documented as a compromise rather than a match. WF34 and MSS-D were characterized against lunar regolith: cohesion 0.06 kPa for WF34 and 0.01 kPa for MSS-D against 0.44 to 0.62 kPa; bulk density 1.4 and 1.3 against 1.4 to 1.6 t/m3; Young’s modulus 1900 and 1000 against about 180 kPa; friction angle 32 plus or minus 2 and 31 plus or minus 2 degrees against 42 degrees [1]. The lunar figures are the top-15-cm Table 9.12 values from the Apollo and Lunokhod penetrometer record, recommended as a depth-averaged Mohr-Coulomb fit rather than a direct measurement, and the friction angle falls as the confining stress rises [6][7]. The operators state the position plainly: “the values for the simulants are in the range but not exactly the lunar soil. This is not problematic as long as the numerical simulation uses the same simulant properties”. Preparation uses “special soil preparation methods and a sand glazer” so that “the underground had the same characteristics at each test run”, with no density figure, relative density target or tonnage published [1]. LAMA is therefore a validation rig for a soil contact model, not an environment simulator, and the model is validated against the simulant that was used.
What it does not reproduce
Section titled “What it does not reproduce”A clean acceleration record. The offload suspension appears in the data. The operators identify a specific run in which “the high negative peak of test run M1234 comes from a hard contact of the sliding part of the weight-offloading suspension to its end block. This is an interference with the effective landing acceleration and has to be separated in the calculation” [2]. More generally, they list weight offloading against the alternatives and concede that model scaling “comes to a practical end… as it leads to unacceptable miniaturization”, that a pendulum or tilted plane “does not allow tests on granular media” and constrains the article’s motion severely, and that weight offloading permits three-dimensional soft soil testing but “however interferences with the offloading device remain” [2]. The 2013 retest quantified the interference against the pendulum it replaced: the LAMA suspension carries a stiffness of 4080 N/m against the earlier pendulum’s 242 N/m, and a damping coefficient of 567 N*s/m is fitted from the combined data so the two rigs’ results can be plotted on the same velocity-against-damper-stroke axes [4].
Free article motion. The rig can suppress real behavior as well as add artifacts. In the 2011 footpad campaign the upward motion of the spherical pads during the slide-out phase was “suppressed here by the robot interface and showed themselves in the higher force levels” [1]. What the pads would have done is inferred from the force record rather than observed, the same kind of inference Surveyor’s own report had to make from imprints and plume craters rather than from a directly observed footpad motion [9].
Repeatable soil. “The main influences of the errors in the test data is caused by the soil properties. Small deviations in the preparation of the soil will lead to large differences in the soil resistance” [1]. The published error figures show where that bites: sinkage 1.1 percent and force 2.6 percent in drop tests, against force 8.7 percent and pitch 32.4 percent in drag tests [1]. The same difficulty runs through the flight-data programs LAMA followed: Surveyor’s own report gives two disjoint cohesion brackets from its vernier engines and its attitude jets that are never reconciled, and Viking’s four surface units carry friction angle and cohesion ranges rather than single values because different reduction methods, footpad penetration, trenching, bearing tests, disagreed on the same ground [9][10]. A controlled ground rig narrows that spread by holding the soil preparation constant, but the LAMA operators’ own error figures show it does not remove it.
Fine regolith at facility scale. MSS-D was restricted to the small drag container “driven by manageability reasons. Too fine grained soils are difficult to handle. They build dust clouds, when they are moved, which affect the measurement equipment and other parts of the test facility” [1]. A drop test therefore lands on quartz sand, not on the fine simulant, and the facility has no answer to the fine-grained dust adhesion behavior that Surveyor measured directly on real lunar material, 250 to 1000 dyne/cm2 on a photometric target and adhesion that grew through the lunar day [9].
Lunar or cometary soil properties. The characterization figures are explicit: the simulants have roughly a tenth to a fiftieth of lunar cohesion, an order of magnitude higher Young’s modulus, and a friction angle 10 degrees lower [1]. For the comet case the operators state outright that “it is acknowledged that surface soil conditions on the comet cannot be reproduced in this type of test facility” [2].
Vacuum, temperature and illumination. None of the three is provided.
Why a robot rig rather than flight-data inference
Section titled “Why a robot rig rather than flight-data inference”Before LAMA, footpad and landing-gear soil interaction for planetary missions was read back from telemetry after the fact rather than reproduced on the ground. Surveyor’s bearing strength ladder, under 0.1 N/cm2 in the top millimeter rising to 4 to 6 N/cm2 averaged over 6 cm, came from imprints left by crushable blocks, footpads and vernier-engine plumes, reduced through Terzaghi bearing capacity theory rather than measured directly, and its own report gives two disjoint cohesion brackets from two different reduction methods that are never reconciled [9]. Apollo’s soil mechanics report is built the same way, from lunar module descent footage, footpad penetration depth at each landing and astronaut debriefing rather than a repeatable test, closing the loop against the pre-Apollo Surveyor model rather than an independent measurement [8]. Viking’s Mars values likewise came from independently reduced footpad penetration, trench geometry, motor currents, surface bearing tests and backhoe touchdowns on the one flight article each lander carried, with no way to rerun the touchdown; the resulting friction angle and cohesion ranges vary by unit, from 14 to 21 degrees and 0.7 to 3.0 kPa for the drift material up to 27 to 32 degrees and 1.5 to 16 kPa for the blocky material [10]. The lunar cohesion and friction-angle figures LAMA’s own simulant characterization is checked against are themselves an inversion, not a measurement: a cone penetrometer cannot separate the two parameters from a single reading, so the Apollo and Lunokhod record fixes one and solves for the other, and the resulting friction angle falls from about 41 degrees at 5 kPa confining stress to about 21 degrees at 100 kPa in the recommended curved envelope [6][7]. The Apollo lunar module’s own footpad bearing pressure, about 4.6 kPa at touchdown, is roughly a fifth of the pressure a person exerts standing on one foot on Earth, which is the order of load LAMA’s footpad campaign was built to reproduce on a soil bed rather than infer from telemetry [6]. LAMA’s robot-and-offload approach exists to give a granular-media landing a repeatable ground rig instead of a single flight event, or a single penetrometer reading, to read back from.
Campaigns run there
Section titled “Campaigns run there”Lunar lander footpad shapes, 2011. Four footpads, spherical and flat-with-rounded-edges in 30 and 40 cm chord at 4 cm height, tested at the MoonNEXT landing envelope: 2 plus or minus 1 m/s vertical, 0 to 1 m/s horizontal, 2.5 plus or minus 2.5 degrees attitude, 0.5 degrees per second rate, with 125 to 300 kg of an 800 kg lander on the pad [1]. At 200 kg and 3 m/s the measured sinkage and peak force were 126 mm at 13.2 kN for the 300 mm spherical pad, 115 mm at 13.6 kN for the 300 mm flat pad, 80 mm at 25.0 kN for the 400 mm spherical and 66 mm at 28.3 kN for the 400 mm flat. Drag tests at 30 mm depth and 1 m/s found the spherical pads carrying 25 to 125 percent higher vertical and lateral loads than the flat ones [1]. The conclusion was that spherical pads slide rather than dig in, and that a 78 percent increase in pad size buys about 60 percent less sinkage [1], a size-versus-sinkage trade of the same kind Viking’s blocky and drift units showed at full lander scale, where the denser, coarser unit carried a higher friction angle and a wider cohesion range than the finer drift material [10].
Philae touchdown requalification, 2012 to 2013. Philae’s original qualification used a 3.96 m pendulum rig between 1996 and 2002, which could not touch down on loose material and constrained the lander’s motion [2][4]. When the target changed from comet 46P/Wirtanen to the more massive 67P/Churyumov-Gerasimenko the landing velocity and kinetic energy rose, and the lander was already at the launch site, so the design could not be changed. Four baseline and three special test groups ran at 0.1 to 1.1 m/s vertical and 0 to 0.21 m/s lateral, at 0 and 17 degrees pitch, with the flywheel off, slow and fast, onto wood, oiled steel, WF34, MSS-D, concrete and a slope with mixed surface [2]. Three findings matter. The touchdown indicator’s detection floor is higher on soft ground, 0.5 m/s against 0.2 m/s on hard surfaces [2]. The tilt limiter intended to hold plus or minus 3 degrees was measured allowing “at least plus or minus 9 degrees”. MSS-D behaved closer to hard ground than WF34 did, with the ice screws sinking less but retracting much harder in MSS-D [2].
Philae’s first touchdown at Agilkia gave a way to check the ground work against a real landing. The damper potentiometer trace from that touchdown, read through a lumped two-mass spring-damper model of the lander, backs out a comet surface compressive strength of about 2 kPa for a constant-strength soil model or 3 kPa per meter for a depth-dependent one, converging with an independent multi-body simulation on 1.5 to 2 kPa once ground slope is corrected for [5]. That figure rests on a single event with only a handful of time-resolved damper positions in the first 200 ms of contact, assumes all three feet struck soil at once even though the imagery suggests one foot hit a boulder strut, and extrapolates past the 135 mm depth the model is stated to be valid for to fit penetration depths as deep as 0.73 m [5]. The comet strength the ground campaign was rehearsing against turned out to be lower than either simulant’s characterized cohesion, which is consistent with the operators’ own caveat that comet soil conditions were not expected to be reproduced in the facility [2]. It is also well below the lunar range LAMA’s own simulants were built against, 0.44 to 0.62 kPa in the top 15 cm by the Apollo and Lunokhod record, so the two bodies the facility has been used to prepare for sit on opposite sides of the simulant’s characterized strength rather than bracketing it [6][7].
MMX rover preliminary model, 2020. Drop tests with the preliminary model of the MMX rover were run in LAMA, which is the most recent published evidence that the facility is in use [3]. No campaign report gives the conditions or the results, which leaves the MMX case in the same position Apollo’s own soil mechanics report was in before a dedicated test rig existed: a landing whose ground interaction has to be read back from whatever instrumented record the mission itself returns [8].
References
- Schröder, S., Witte, L. and van Zoest, T. (2011). Footpad-Terrain Interaction Tests with the Robotic Landing and Mobility Test Facility (LAMA)
. International Astronautical Congress. Source
BibTeX
@inproceedings{schroder2011footpad, title = {Footpad-Terrain Interaction Tests with the Robotic Landing and Mobility Test Facility (LAMA)}, author = {Schröder, Silvio and Witte, Lars and van Zoest, Tim}, booktitle = {International Astronautical Congress}, address = {Cape Town}, year = {2011}, url = {https://elib.dlr.de/102762/} } - Schröder, S., Biele, J., Block, J., Roll, R., Ulamec, S. and Witte, L. (2013). Philae Landing Test at the Landing and Mobility Test Facility (LAMA)
. International Astronautical Congress, IAC-13, A3, 4, 3. Source
BibTeX
@inproceedings{schroder2013philae, title = {Philae Landing Test at the Landing and Mobility Test Facility (LAMA)}, author = {Schröder, Silvio and Biele, Jens and Block, Joachim and Roll, Reinhard and Ulamec, Stephan and Witte, Lars}, booktitle = {International Astronautical Congress, IAC-13, A3, 4, 3}, address = {Beijing}, year = {2013}, url = {https://elib.dlr.de/103154/} } - (2020). Drop tests in the DLR Landing and Mobility Test Facility. dlr.de/en/images/2020/3/preliminary-model-drop-test
BibTeX
@misc{dlrlamammx, title = {Drop tests in the {DLR} Landing and Mobility Test Facility}, organization = {DLR}, year = {2020}, url = {https://www.dlr.de/en/images/2020/3/preliminary-model-drop-test} } - Witte, L., Schroeder, S., Kempe, H., van Zoest, T., Roll, R., Ulamec, S., Biele, J. and Block, J. (2014). Experimental Investigations of the Comet Lander Philae Touchdown Dynamics
. Journal of Spacecraft and Rockets. Source
BibTeX
@article{witte2014experimental, title = {Experimental Investigations of the Comet Lander Philae Touchdown Dynamics}, author = {Witte, Lars and Schroeder, Silvio and Kempe, Henning and van Zoest, Tim and Roll, Reinhard and Ulamec, Stephan and Biele, Jens and Block, Joachim}, journal = {Journal of Spacecraft and Rockets}, volume = {51}, pages = {1885-1894}, year = {2014}, doi = {10.2514/1.a32906}, abstract = {The comet lander Philae (as part of Europe’s Rosetta mission) is en route to its target, 67/P Churyumov-Gerasimenko. With landing operations coming up at the end of 2014, a partial retesting of the Philae lander’s touchdown system was carried out in spring of 2013. Intensive testing was performed as part of Philae’s design and verification program approximately 10 years ago. However, the new test series specifically addresses touchdown conditions that have been out of capability of the pendulum test facility used at those times. Thus, the follow-up tests focus on touchdown conditions such as asymmetric loads, effects from terrain undulation, and the effect of granular soil mechanics, which could not be studied sufficiently in the original tests. This paper provides insight into the touchdown system of the Philae lander, the characteristics of the used test facility, its weight offloading operating mode, and the specific application to a small-body landing test. The results of the study are presented and discussed in terms of their importance to the ongoing landing preparations.} } - Roll, R., Witte, L. and Arnold, W. (2016). ROSETTA lander Philae – soil strength analysis
. Icarus. Source
BibTeX
@article{roll2016rosetta, title = {ROSETTA lander Philae – soil strength analysis}, author = {Roll, Reinhard and Witte, Lars and Arnold, Walter}, journal = {Icarus}, volume = {280}, pages = {359-365}, year = {2016}, doi = {10.1016/j.icarus.2016.07.004} } - Carrier, W. D. I., Olhoeft, G. R. and Mendell, W. (1991). Physical Properties of the Lunar Surface
. Lunar Sourcebook: A User's Guide to the Moon. Source
BibTeX
@incollection{carrier1991physical, title = {Physical Properties of the Lunar Surface}, author = {Carrier, W. David, III and Olhoeft, Gary R. and Mendell, Wendell}, editor = {Heiken, Grant H. and Vaniman, David T. and French, Bevan M.}, booktitle = {Lunar Sourcebook: A User's Guide to the Moon}, pages = {475--594}, publisher = {Cambridge University Press}, chapter = {9}, year = {1991}, url = {https://www.lpi.usra.edu/publications/books/lunar_sourcebook/pdf/Chapter09.pdf} } - Heiken, G. H., Vaniman, D. T. and French, B. M. (1991). Lunar Sourcebook: A User's Guide to the Moon
. Endeavour. Source
BibTeX
@book{heiken1991lunar, title = {Lunar Sourcebook: A User's Guide to the Moon}, author = {Heiken, Grant H. and Vaniman, David T. and French, Bevan M.}, journal = {Endeavour}, volume = {16}, pages = {96}, publisher = {Cambridge University Press}, year = {1991}, doi = {10.1016/0160-9327(92)90014-g} } - Scott, R. F. (1975). Apollo Program Soil Mechanics Experiment: Final Report
. California Institute of Technology, NASA Contract NAS 9-11454. Source
BibTeX
@techreport{scott1975apollo, title = {Apollo Program Soil Mechanics Experiment: Final Report}, author = {Scott, Ronald F.}, number = {NASA Contract NAS 9-11454}, institution = {California Institute of Technology}, year = {1975}, url = {https://ntrs.nasa.gov/citations/19750023910}, abstract = {The soil mechanics investigation was conducted to obtain information relating to the landing interaction of the lunar module (LM) with the lunar surface, and lunar soil erosion caused by the spacecraft engine exhaust. Results obtained by study of LM landing performance on each Apollo mission are summarized.} } - Surveyor Scientific Evaluation Advisory Team. (1968). Surveyor Project Final Report, Part 2: Science Results
. Jet Propulsion Laboratory, NASA-CR-101584. Source
BibTeX
@techreport{surveyor1968surveyorb, title = {Surveyor Project Final Report, Part 2: Science Results}, author = {{Surveyor Scientific Evaluation Advisory Team}}, number = {NASA-CR-101584}, institution = {Jet Propulsion Laboratory}, year = {1968}, url = {https://ntrs.nasa.gov/citations/19690019967} } - Moore, H. J., Hutton, R. E., Clow, G. D. and Spitzer, C. R. (1987). Physical Properties of the Surface Materials at the Viking Landing Sites on Mars
. U.S. Geological Survey, Professional Paper 1389. Source
BibTeX
@techreport{moore1987physical,
  title = {Physical Properties of the Surface Materials at the Viking Landing Sites on Mars},
  author = {Moore, Henry J. and Hutton, Robert E. and Clow, Gary D. and Spitzer, Cary R.},
  number = {Professional Paper 1389},
  institution = {U.S. Geological Survey},
  year = {1987},
  doi = {10.3133/pp1389},
  abstract = {Estimates of water and carbon dioxide in samples analyzed in_ the gas chromatograph-mass spectrometer for the Molecular Analysis Experiment-----------------------}
}