NASA ARC Roverscape
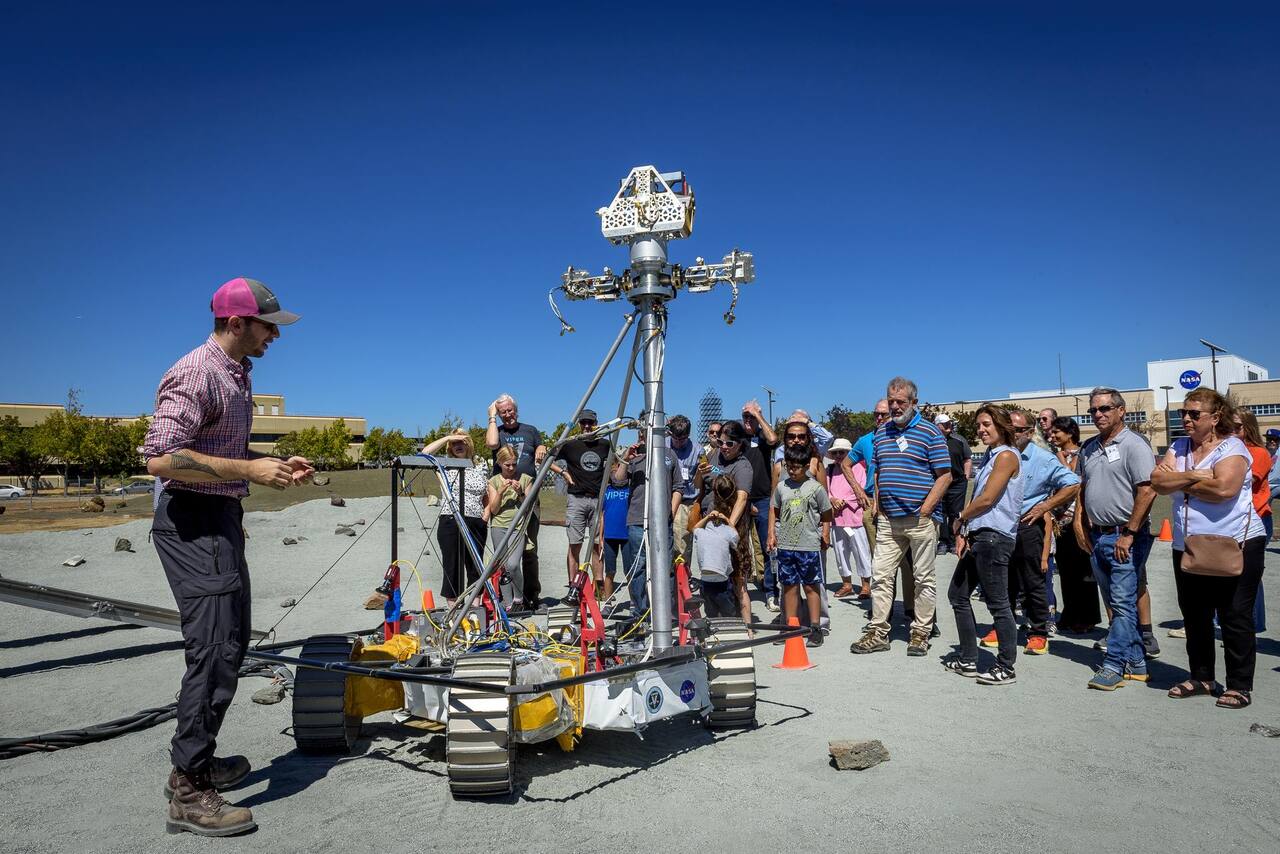 NASA/Don Richey. Public domain (NASA / US government work).
A rover’s navigation and hazard-detection software has to be exercised on ground that looks like the terrain it will fly over before anyone trusts it on a mission, and orbit, thermal vacuum and radiation chambers do nothing for that: none of them puts a wheel on a slope, a boulder field or a shadow. NASA ARC answers that gap with an outdoor lot rather than an indoor rig. The Roverscape is a two-acre outdoor lunar analogue terrain field, designed to support testing of rover locomotion, navigation and operations, and also suitable for simulating planetary surface missions [4]. Its free surface is pea gravel rather than a regolith simulant, laid out with boulder distributions and an average surface albedo of 8 percent chosen to resemble lunar regolith [2]. It is the terrain the Intelligent Robotics Group drives on, and it is where the K10 planetary rover was operated from the International Space Station in 2013 [1][3].
A 2025 NASA state-of-practice survey gives the field’s area as 11,500 m2, larger than the “two acres” (about 8,100 m2) the site’s own operators state in the papers describing the 2013 and 2017 campaigns [4]; nothing published reconciles the two figures.
The Arc Jet Complex shares the center but nothing else, and has its own page: it is run by a different branch, in different buildings, for a different purpose.
Laboratory data
Section titled “Laboratory data”| Parameter | Value |
|---|---|
| Operator | NASA ARC, Intelligent Robotics Group [1] |
| Location | Moffett Field, California, United States |
| Commissioned | Not published; in use for Surface Telerobotics in summer 2013 |
| Type | Outdoor analogue terrain field [4] |
| Floor area | Two acres, approximately 8,100 m2; 11,500 m2 per a later NASA survey [2][4] |
| Capabilities | Terrain field |
| Simulant or terrain | Pea gravel free surface, boulder distributions, 8 percent albedo |
| Instrumentation | Not published as installed capability; users bring their own metrology |
| Ground truth | Site imagery at 0.75 m/pixel and a 1.5 m/post elevation model |
| Fidelity limits | 1 g, Earth atmosphere, ambient daylight, pea gravel not simulant [2] |
| Access | Not published; no external user route, lead time or fee schedule located |
| Cited by | VIPER, photographed running its Moon Gravity Representative Unit test platform on the surface |
Orbital-resolution imagery of the site at 0.75 m/pixel and a digital elevation map at 1.5 m/post were produced for mission planning, both deliberately degraded to match what is available for the Moon, which gives the site a ground truth layer that is independent of any rover driving on it: surface-level survey data can be compared against what orbital resolution would have shown [1]. Campaign metrology is otherwise brought by the user, for example the multi-dot laser projector and camera mounted on the leading edge of K-REX2 for the virtual bumper work [2].
Capabilities
Section titled “Capabilities”Terrain field
Section titled “Terrain field”| Parameter | Value |
|---|---|
| Working volume | Two acres, approximately 8,100 m2; no layout plan published |
| Test article limits | Full-scale rovers K10 and K-REX2 run here; VIPER’s MGRU has been photographed on the surface [1][2] |
| Vacuum | Not applicable; outdoors at Earth ambient pressure |
| Temperature | Not controlled; Moffett Field outdoor conditions |
| Illumination | Ambient; night running used for directional lighting cases |
| Simulant or terrain | Pea gravel, boulder distributions, 8 percent average albedo |
| Slope | Not published; no slope inventory or settable slope rig described |
| Gravity offload | Not applicable; weight-equivalent test platforms used instead |
Everything published about the field’s physical construction fits in two sentences of a computer vision paper: it is a two-acre outdoor planetary analog terrain with boulder distributions and an average surface albedo of 8 percent similar to lunar regolith, whose free surface is covered in a layer of pea gravel and not a regolith simulant, for reasons of practicality [2]. Obstacle test cases have been designed to mirror the geometric possibilities likely in craters at the lunar poles. No tonnage, grain size distribution, bearing capacity or preparation procedure between tests is published.
Illumination is not an engineered capability but it is used as a variable. Day and night tests have been run to recreate direct and indirect illumination conditions, the two chosen so that total incident illumination and dominant directionality were similar, which is how a structured-light hazard detector was evaluated on the site. There is no solar simulator and no settable solar elevation angle.
Lunar weight is approximated elsewhere by building a weight-equivalent test platform rather than by offloading; VIPER’s Moon Gravity Representative Unit is such a platform, its mass tuned to give Earth-gravity wheel loads matching the flight rover’s lunar wheel loads, and it has been photographed running on the Roverscape surface. The MGRU’s mobility and terramechanics test program itself runs at a different NASA test bed and is not described here.
Instrumentation
Section titled “Instrumentation”The site has no published installed metrology. What exists as facility infrastructure is the prior survey: satellite imagery of the site degraded to 0.75 m/pixel and a 1.5 m/post digital elevation model, both chosen to match the orbital data resolution available for the Moon, plus a control shelter from which operations are run [1]. Everything measured about a test article is brought by the campaign.
What it does not reproduce
Section titled “What it does not reproduce”Gravity and atmosphere. The field is at 1 g under Earth atmosphere and ambient daylight, and there is no offload rig [1]. Lunar weight is approximated instead by building a weight-equivalent test platform, the approach behind the VIPER Moon Gravity Representative Unit that has been driven here.
Regolith. The surface is pea gravel, an explicit practicality substitution by the operators [2], so nothing about dust, sinkage, cohesion or tribology transfers. The Roverscape tests navigation, perception and operations, not terramechanics.
Repeatability of the terrain. No preparation procedure between tests is published, and the field is outdoors, so surface state is a condition of the day rather than a set variable.
Campaigns run there
Section titled “Campaigns run there”Surface Telerobotics, summer 2013. Three astronauts of ISS Expedition 36 remotely operated the K10 planetary rover on the Roverscape from orbit, simulating a mission in which an astronaut in lunar orbit deploys a radio telescope on the lunar far side [1][3]. A later paper from the same NASA group gives each of the three sessions as 3.5 hours [3], a figure the campaign paper’s own numbers, 40 minutes of crew training plus two hours of operations per session, do not add up to and that neither paper explains.
Session 1, on 17 June 2013 [1], surveyed the site and began deployment of a simulated telescope array, using surface-level survey data to assess terrain obstacles, slopes and undulations below the resolution of the orbital imagery or ambiguous because of its nadir pointing; session 2, on 26 July, deployed all three arms of the array and ran ahead of schedule into the inspection phase; session 3, on 20 August, started midway through deployment and performed remote visual inspection. Commanding ran over Ku-band by a combination of supervisory command sequencing and manual discrete commanding, for 11 hours of operation and 221.43 m, 170.14 m and 200.15 m driven across the three sessions [1].
Structured-light hazard detection, published 2017. A multi-dot laser projector and camera mounted on the leading edge of the K-REX2 rover were evaluated on the field against obstacle cases designed to mirror the geometry likely in lunar polar craters, in day and night runs chosen so that total incident illumination and dominant directionality matched [2].
VIPER, ongoing. The Moon Gravity Representative Unit, a weight-equivalent platform built to VIPER’s lunar wheel loads, has been photographed driving on the Roverscape surface. No source found states what test objective that run served, or whether it is a routine part of VIPER’s mobility and navigation development rather than a one-off imaging opportunity [4].
What is not established
Section titled “What is not established”The field’s own operators have published almost nothing about its physical construction: no tonnage or grain size distribution for the pea gravel, no bearing capacity figure, no preparation procedure run between test campaigns, and no slope inventory. Nothing published states when the site was commissioned; the earliest documented use is the 2013 Surface Telerobotics campaign [1][3]. The two published area figures, 8,100 m2 and 11,500 m2, are not reconciled by any source found [2][4], and no external user access route, lead time or fee schedule has been located. The MGRU photograph is the only evidence found that VIPER has used the site at all, and no source found states what that test was for [4].
References
- Bualat, M., Schreckenghost, D., Pacis, E., Fong, T., Kalar, D. and Beutter, B. (2014). Results from Testing Crew-Controlled Surface Telerobotics on the International Space Station
. iSAIRAS - International Symposium on Artificial Intelligence, Robotics and Automation in Space, 20150007985. Source
BibTeX
@inproceedings{bualat2014results, title = {Results from Testing Crew-Controlled Surface Telerobotics on the International Space Station}, author = {Bualat, Maria and Schreckenghost, Debra and Pacis, Estrellina and Fong, Terrence and Kalar, Donald and Beutter, Brent}, booktitle = {iSAIRAS - International Symposium on Artificial Intelligence, Robotics and Automation in Space}, number = {20150007985}, institution = {NASA}, address = {Montreal, Quebec}, year = {2014}, url = {https://ntrs.nasa.gov/citations/20150007985}, abstract = {During Summer 2013, the Intelligent Robotics Group at NASA Ames Research Center conducted a series of tests to examine how astronauts in the International Space Station (ISS) can remotely operate a planetary rover. The tests simulated portions of a proposed lunar mission, in which an astronaut in lunar orbit would remotely operate a planetary rover to deploy a radio telescope on the lunar far side. Over the course of Expedition 36, three ISS astronauts remotely operated the NASA "K10" planetary rover in an analogue lunar terrain located at the NASA Ames Research Center in California. The astronauts used a "Space Station Computer" (crew laptop), a combination of supervisory control (command sequencing) and manual control (discrete commanding), and Ku-band data communications to command and monitor K10 for 11 hours. In this paper, we present and analyze test results, summarize user feedback, and describe directions for future research.} } - Nefian, A. V., Wong, U. Y., Dille, M., Bouyssounouse, X., Edwards, L. and To, V. (2017). Structured Light-Based Hazard Detection for Planetary Surface Navigation
. IEEE Winter Conference on Applications of Computer Vision, 20170009200. Source
BibTeX
@inproceedings{nefian2017structured, title = {Structured Light-Based Hazard Detection for Planetary Surface Navigation}, author = {Nefian, Ara V. and Wong, Uland Y. and Dille, Michael and Bouyssounouse, Xavier and Edwards, Laurence and To, Vinh}, booktitle = {IEEE Winter Conference on Applications of Computer Vision}, number = {20170009200}, pages = {2665-2671}, institution = {NASA Ames Research Center}, year = {2017}, doi = {10.1109/iros.2017.8206090}, abstract = {This paper describes a structured light-based sensor for hazard avoidance in planetary environments. The system presented here can also be used in terrestrial applications constrained by reduced onboard power and computational complexity and low illumination conditions. The sensor consists on a calibrated camera and laser dot projector system. The onboard hazard avoidance system determines the position of the projected dots in the image and through a triangulation process detects potential hazards. The paper presents the design parameters for this sensor and describes the image based solution for hazard avoidance. The system presented here was tested extensively in day and night conditions in Lunar analogue environments. The current system achieves over 97% detection rate with 1.7% false alarms over 2000 images.} } - Schmaus, P., Leidner, D., Bayer, R., Pleintinger, B., Krüger, T. and Lii, N. Y. (2019). Continued Advances in Supervised Autonomy User Interface Design for METERON SUPVIS Justin
. IEEE Aerospace Conference. Source
BibTeX
@inproceedings{schmaus2019continued, title = {Continued Advances in Supervised Autonomy User Interface Design for METERON SUPVIS Justin}, author = {Schmaus, Peter and Leidner, Daniel and Bayer, Ralph and Pleintinger, Benedikt and Krüger, Thomas and Lii, Neal Y.}, booktitle = {IEEE Aerospace Conference}, pages = {1-11}, address = {Big Sky, Montana}, year = {2019}, doi = {10.1109/aero.2019.8741885}, abstract = {The exploration of the universe remains a challenging endeavor, constantly pushing the limits of technology. Of special interest is the investigation of the other planets of our solar system such as Mars, which has been examined by various tele-operated and (semi-) autonomous satellites and landers. But an important milestone that is needed for a deeper understanding of the planet is still missing: A crewed landing. In order to send humans to such a remote location, an infrastructure for the landing crew including an energy supply, a habitat, and a return vehicle needs to be provided on the surface of the planet. The construction and maintenance of these structures is envisioned to be done by semiautonomous robots that are commanded from orbiting spacecrafts. The teleoperation of such ground-based robots poses high demands on the capabilities of the system including robot autonomy, orbiter-robot communication, and human-robot interface design. The METERON SVPVIS Justin space telerobotics experiment suite has been initiated by the German Aerospace Center (DLR) together with the European Space Agency (ESA) to investigate the requirements for such a system and evaluate an approach. During the experiment sessions, astronauts onboard the International Space Station (ISS) command DLR's humanoid service robot Rollin' Justin on Earth to execute complex surveillance, service, and repair tasks in a simulated Martian solar farm. The robot uses its local intelligence to support the astronaut operator upon task completion allowing a simple intuitive command interface and lowering the requirements on the communication link. This work gives an overview of the developed robotic system, communication link, and tablet computer user interface (UI). In particular the tight coupling between the autonomy system of the robot and the UI, that allows the intuitive robot commanding including action parameterization, is described in detail. The first space-ground experiment sessions of METERON SUPVIS Justin were conducted in August 2017, and March 2018 by four astronauts in total. During the first session, three astronauts demonstrated the operational readiness of our system by commanding Rollin' Justin to perform surveillance and inspection tasks. The astronauts were even able to successfully command the robot in scenarios, which were not trained prior to their spaceflight. This was possible, because our astronaut-robot collaboration concept efficiently guides the operator towards task completion. We used this property in the second experiment session to evaluate our system in even more complex scenarios. While in the first session it was sufficient for the astronaut to select the correct commands, the operator was now required to manually parameterize some of the commands to optimize the task outcome. By that, the robot has been successfully commanded to perform complex maintenance and adjustment tasks in the simulated Martian solar farm. In this work, we evaluate the preliminary results of the space-ground experiments and discuss the feedback we received from the astronauts and its impact on future space telerobotics UI design.} } - Mulvaney, J., Arney, D., Williams, C., Morel, J., Stockdale, C., Whitlock, C. and Balaji, V. (2025). In-Space Servicing, Assembly, and Manufacturing (ISAM) State of Play, 2025 Edition
. NASA, 20250008988. Source
BibTeX
@techreport{nasa2025space,
  title = {In-Space Servicing, Assembly, and Manufacturing (ISAM) State of Play, 2025 Edition},
  author = {Mulvaney, John and Arney, Dale and Williams, Christina and Morel, Jose and Stockdale, Christopher and Whitlock, Christopher and Balaji, Vishruth},
  number = {20250008988},
  institution = {NASA},
  year = {2025},
  url = {https://ntrs.nasa.gov/citations/20250008988},
  abstract = {The future of spaceflight will yield increasingly more ambitious missions to support civil, national security,
and commercial space sectors. Achieving some of these missions will not be feasible by launching an
integrated, fully functioning system on a single launch vehicle. Future science and human exploration
missions will require payloads that are larger than any foreseeable launch vehicle fairing, national security
missions will require persistent assets that are mobile and resilient, and commercial space missions will
require cost-effective ways to update to the latest technology on orbit.

In-space Servicing, Assembly, and Manufacturing (ISAM) can vastly expand the performance, availability,
and lifetime of space systems compared to the traditional paradigm of launching an asset with no intent
to ever interact with it again. ISAM capabilities foster an ecosystem that changes the space operations
paradigm, creating the foundation for sustainable exploration and serving as a multiplier for other
capabilities like space logistics, power generation, and reusability.

Previous achievements in ISAM have enabled ambitious human and robotic space missions. The
assembly, operation, and maintenance of NASA’s International Space Station (ISS); servicing missions to
the Hubble Space Telescope (HST); and Northrop Grumman’s Mission Extension Vehicle (MEV)
demonstrate the dramatic operational missions that can be achieved using ISAM capabilities. Many
current and upcoming flight demonstrations are advancing areas that will enable the next generation of
civil, national security, and commercial space missions.

This document describes the current state of ISAM missions, activities, and technologiesto the best ability
of the authors. Compiling and organizing the available ISAM capabilities will help mission designers
incorporate ISAM technologies into their concepts, create the starting point for technology development
plans and roadmaps, and provide technologists a survey of the field they are developing. This document
divides the ISAM capabilities into 11 functional capability areas that describe the functions or activities
that can be performed in space using ISAM.}
}