NASA KSC Granular Mechanics and Regolith Operations Laboratory
NASA/Kim Shiflett. Public domain (NASA / US government work).
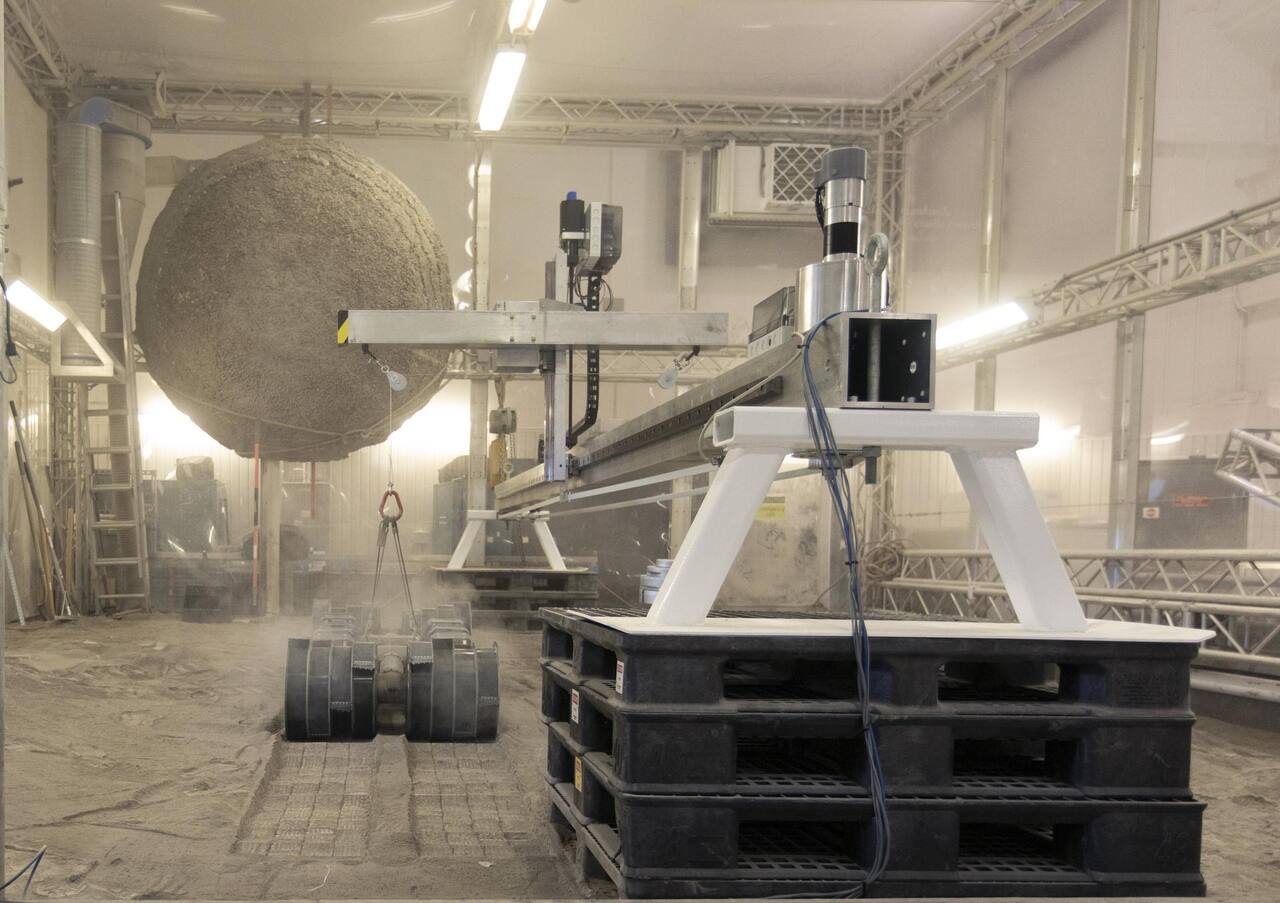
The Granular Mechanics and Regolith Operations laboratory at NASA KSC holds NASA’s largest indoor lunar simulant beds: 120 t of BP-1 over a 25 x 25 ft bin 3.5 ft deep, a second bin of 2 t of JSC-1A, a two-axis gantry excavation test stand spanning the main bin, and a standing geotechnical bench used to condition and characterize the beds between runs [1][2][7]. Around those bins the laboratory also operates a dirty thermal vacuum chamber with a four-axis gantry inside it, a competition scale enclosed arena, an actuator test rig, dust and plume diagnostics, and a machine shop [7][8][11].
The laboratory sits inside Swamp Works, which is the parent organization at Kennedy rather than a building or a facility of its own [7].
Laboratory data
Section titled “Laboratory data”| Parameter | Value |
|---|---|
| Operator | NASA KSC, Granular Mechanics and Regolith Operations laboratory, within Swamp Works [7] |
| Location | NASA KSC, Florida, United States |
| Commissioned | Main bin completed 2013 [1] |
| Type | Simulant bins, dirty thermal vacuum chamber, gantries, geotechnical bench [1][2][7][8] |
| Floor area | Not published |
| Capabilities | Two simulant bins, the Artemis Arena, the ASSIST chamber, the ARGO and excavation gantries [1][2][7][8][11] |
| Capabilities, benches | Geotechnical bench, bevameter, actuator rig, plume and dust diagnostics, machine shop [1][4][7] |
| Simulant or terrain | BP-1, 120 t; JSC-1A, 2 t; LHS-1, ICN-LHT-1G and RDW-LHT-1G-h per campaign [2][7] |
| Instrumentation | OptiTrack, 6 cameras, under 0.3 mm; load cells; cone and pocket penetrometers; vane shear [2][3][4] |
| Ground truth | Motion capture pose, load cell force, destructive core sampling for bulk density [2][3] |
| Fidelity limits | 1 g; simulant, not regolith; bed preparation is the dominant error source [2] |
| Access | KSC partnerships office capability catalog; no published lead time or fee schedule [7][8][11] |
| Cited by | IPEx [3][6], RASSOR [3][5], CubeRover |
Capabilities
Section titled “Capabilities”Planetary Regolith Test Bed
Section titled “Planetary Regolith Test Bed”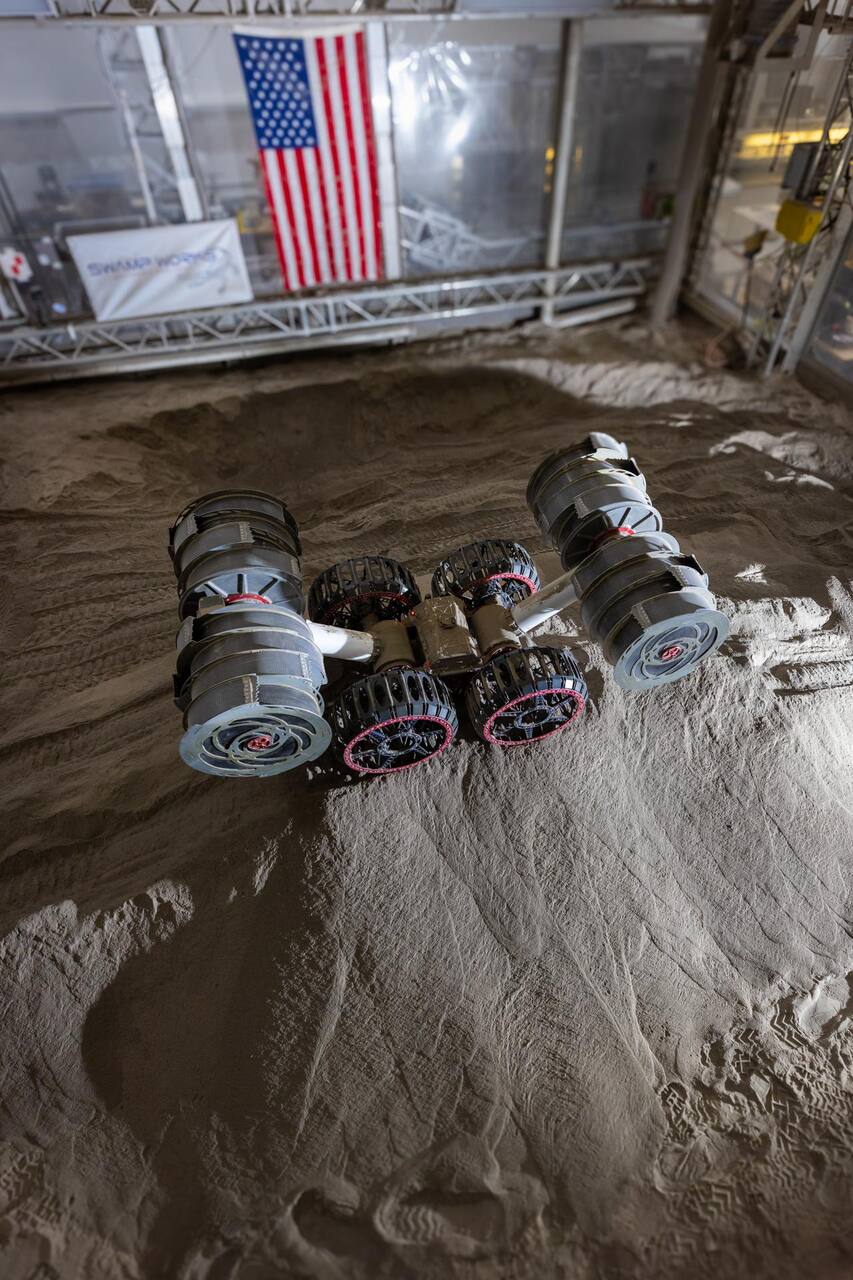
NASA/Frank Michaux. Public domain (NASA / US government work).
| Parameter | Value |
|---|---|
| Working volume | 25 x 25 ft (7.6 m square), 3.5 ft deep; other reports differ, see below [7] |
| Test article limits | Articles run: 30 kg-class IPEx surrogate to RASSOR 2.0 [3] |
| Temperature | Not controlled. Climate-controlled high bay, no thermal capability [1] |
| Simulant or terrain | BP-1, 120 t, about 1 m deep; compacted bulk density 1.75 g/cm3 within 5 percent [3][7] |
| Slope | Set by hand. 20 degrees within 0.5 degrees over 1 m in wheel testing [3]. No maximum published |
| Instrumentation | OptiTrack, 6 cameras, under 0.3 mm; Interface SM-250 drawbar transducer, plus or minus 150 lbf |
The main bin, called the Planetary Regolith Test Bed in the 2016 dust work and the Big Bin in later compaction reports, was completed in 2013 in a climate-controlled facility and holds 120 t of BP-1 to a depth of about 1 m [1]. Published horizontal dimensions vary between reports of the same bin, from 64 m2 through 7.7 x 7.3 m [2] to 8 x 8 m [3], with a bin width of about 7.9 m quoted for the laser path length in the extinction work.
BP-1 is a crushed basalt mare mechanical simulant from the Black Point lava flow near Flagstaff, Arizona, selected because its particle size distribution falls within one standard deviation of Apollo returned soil. Also in use in the bin are LHS-1 highlands simulant from the UCF Exolith Lab, and ICN-LHT-1G and RDW-LHT-1G-h.
Preparation is procedural and manual. For wheel testing the bed is leveled with an 80/20 beam and wide rake, checked with a 24 inch bubble level every 2 ft in X and Y, compacted by dragging a 50 lb weight in a plastic bin in a crosshatch pattern at 50 percent overlap to a bulk density of 1.75 g/cm3 within 5 percent, then raked to leave an approximately 2.5 cm low-density layer on top [3]. For compaction testing a 0.3 m deep pit of 0.6 x 0.6 m or 0.6 x 1.8 m is dug and refilled through a 1 cm mesh screen, raked, then graded by the Excavation Test Stand in 0.5 mm depth increments; initial relative densities of 57 to 60 percent were achieved and below about 48 percent was not practical [3].
Smaller vessels are placed inside the main bin per campaign: a trapezoidal aluminum LHS-1 container 35.5 cm deep, 78.7 x 45.7 cm at the top and 43.1 x 38.1 cm at the base, volume 0.09 m3, set on a tarp to prevent cross-contamination [2]; and a 150 kg simulant bin for the plume surface interaction firings [4].
JSC-1A Lunar Regolith Simulant Bin
Section titled “JSC-1A Lunar Regolith Simulant Bin”| Parameter | Value |
|---|---|
| Simulant or terrain | JSC-1A, 2 t [1][7] |
| Instrumentation | Laser and camera plume erosion sensor [1] |
The second, smaller bin holds 2 t of JSC-1A and is where the plume erosion optical sensor was first developed before the method was scaled up across the main bin [1]. No dimensions, bed depth or preparation procedure are published for it.
Excavation Test Stand
Section titled “Excavation Test Stand”| Parameter | Value |
|---|---|
| Working volume | Two axes spanning the main bin, about 5 m horizontal and 1 m vertical travel |
| Test article limits | Horizontal force limited to 300 N |
| Slope | Used to grade the bed in 0.5 mm depth increments |
| Gravity offload | Not used as one, although designed with the travel and acceleration for it |
| Instrumentation | ATO LCMA-DYDW-005 triaxial load cells, 2 x 500 N, 0 to 92.6 kPa under the plate |
Source: [2].
The Excavation Test Stand spans the main bin as a two-axis gantry, controlled from LabVIEW, velocity-limited to 400 mm/s in X and 25 mm/s in Z for compaction work [2]. It was built to characterize bucket drum excavators and has since been retrofitted for compaction tool work, where it both grades the bed and drives the tool.
ASSIST chamber
Section titled “ASSIST chamber”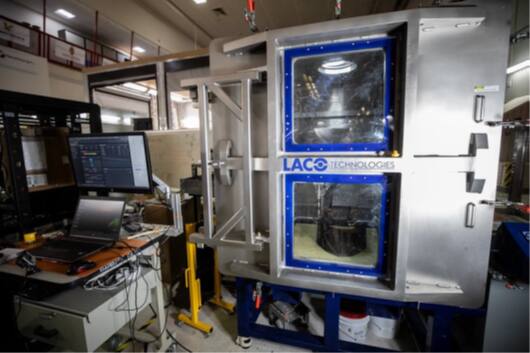
NASA/NASA KSC. Public domain (NASA / US government work).
| Parameter | Value |
|---|---|
| Working volume | 1.47 x 1.47 x 1.18 m internal; 1.4 x 1.1 x 1.4 m with the Mega-Shroud installed [8] |
| Test article limits | 3130 kg payload, floor loading to 6.7 MPa; full front face is a door |
| Vacuum | 760 to 3.5 x 10^-6 torr empty; 1 x 10^-5 torr with the gantry installed |
| Temperature | Shrouds below -200 C; walls capped at 150 C by the elastomeric flange seals [8][9] |
| Illumination | Xenon arc lamp, 7.14 kW, 280,000 lm, through the 25.4 cm silica top viewport [8] |
| Simulant or terrain | Removable beds, 12.5 mm and 50 mm deep; ICN-LHT-1G and LHS-1 run to date [8][9][2] |
| Instrumentation | Inficon MPH200M residual gas analyzer to 200 AMU, on its own turbo and roughing pumps [8] |
ASSIST is a dirty thermal vacuum chamber sized deliberately between the two classes of chamber that already existed. Its operators describe the gap it fills: dirty thermal vacuum systems are “either large, facility-based chambers with long test turnaround times, high upkeep costs, and expensive access fees, or they are significantly smaller with limited technology demonstration volume and configuration capabilities”, and ASSIST “fits between these two extremes with a large internal volume but quick turnaround testing” [8]. The technology focus areas the operators name for it are excavation, site preparation, construction and in-situ resource utilization. It admits regolith and volatiles, which most qualification-class chambers do not. It was in service before 2021 and was retrofitted for hot reactor work under the Game Changing Development molten regolith electrolysis project for the late 2024 demonstration [8][9].
The pressure envelope is a rectangular chamber whose entire front face is a door, so a test fixture can occupy the full 1.47 x 1.47 m cross-section and be placed with a forklift rather than lowered through a hatch [8]. Mounting is by quarter-inch 20 blind holes on a 15.24 cm (6 in) square grid across three internal walls, each rated to 445 N in shear, which sets the practical limit on cantilevered fixtures. Feedthroughs run on five faces, from KF25 gauge ports to the ISO350-K on the rear and the 25.4 cm fused silica viewport on top [8].
Pumping is by an EBT2400 turbomolecular pump on an ISO250-K port behind a roughing stage, with the gate valve to the turbo opening at about 9 x 10^-1 torr [8]. A specific medium vacuum setpoint down to 1 torr can be held to a control band, for example plus or minus 3 torr, which is how martian surface pressure is reproduced. The chamber pump is rated to 1.33 x 10^-4 Pa, about 1 x 10^-6 torr; during the molten regolith electrolysis campaign the chamber with the reactor inside was evacuated to 10^-4 torr and the reactor interior to 10 torr [9].
Cold conditions are produced by shrouds rather than by a cold wall. Two Cryomech helium-loop cryocoolers are available, an AL600 giving 600 W at -190 C with a -250 C base temperature and an AL325 giving 100 W at -250 C with a -261 C base, and the operators state that they were chosen over a liquid nitrogen loop on cost and facility grounds, with the trade acknowledged: helium systems reach lower temperatures but their heat rejection wattage is limited, so the shrouds inside the chamber cannot reach either cryocooler’s base temperature [8]. The 0.27 x 0.27 x 0.25 m Mini-Shroud reached below -200 C in about two hours; the 1.4 x 1.1 x 1.4 m Mega-Shroud was still uncharacterized thermally at publication [8]. Test hardware can also be bolted directly to a cryohead, in which case the temperature reached depends on coupling area, isolation from the chamber wall and the article’s thermal mass.
The chamber is quoted two ways in the operators’ own documents, and the difference is the shroud: the bare internal dimensions are 1.47 x 1.47 x 1.18 m, while the test volume advertised alongside it, 1.4 x 1.1 x 1.4 m, is the internal volume of the Mega-Shroud [8].
The retrofit for hot reactor work was driven by the opposite problem, a reactor running near 1600 C inside a chamber whose seals fail at 150 C. The chamber walls were given a cooling system of 7 kW, a separate oil chiller of 10 kW was added to cool exhaust gases and in-vacuum hardware, a ceramic firebrick pallet protected the chamber floor under the reactor, and wall temperature and vacuum level were monitored in real time through the run [9].
Power into the chamber is two Keysight supplies, an N8932A at 200 V and 210 A and an N8931A at 80 V and 510 A, 15 kW each, on copper transmission lines, plus a 10 kW induction coil supply [8]. Facility feeds are one 480 V three-phase 30 A, three 208 V three-phase 60 A and two 120 V single-phase 20 A circuits.
Simulant beds in the chamber are removable rather than fixed: a 794 x 720 mm bed takes up to 50 mm of simulant, screeded level with excess captured in channels on all four faces and garolite plates underneath for thermal isolation, and a 12.5 mm deep bed sits in the Universal Build Plate [8]. No tonnage is published.
ARGO gantry
Section titled “ARGO gantry”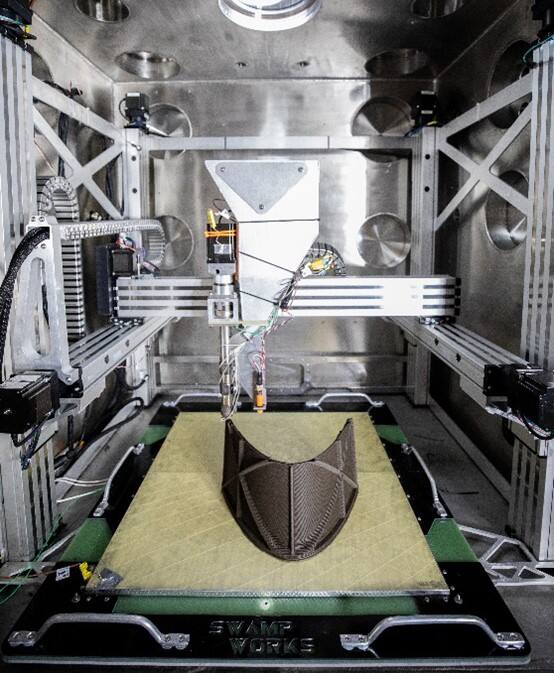
NASA/NASA KSC. Public domain (NASA / US government work).
| Parameter | Value |
|---|---|
| Working volume | Build volume 754 x 754 x 805 mm; space claim 1320 x 1070 x 1370 mm |
| Test article limits | 90 kg maximum payload on the moving axes |
| Vacuum | Not a vacuum system. Works inside ASSIST, which reaches 1 x 10^-5 torr with it fitted |
| Temperature | Gantry -10 to 80 C, the actuator manufacturer’s range; heated bed ambient to 100 C |
| Simulant or terrain | Universal Build Plate, 12.5 mm bed, or the separate 50 mm bed, 794 x 720 mm |
| Instrumentation | National Instruments four-card acquisition for thermocouples and load cells |
Source: [8].
ARGO is a four-axis motion system built to work in dust and vacuum. It is the manipulation half of a pair with the ASSIST chamber: the chamber supplies the pressure, temperature and atmosphere, the gantry supplies controlled motion inside it, and the two are used together for additive construction, site preparation tooling and regolith handling [8]. It also runs at ambient pressure outside the chamber. The name ARGO is used by Kennedy for two different things, the gantry itself and the wider capability set that bundles the chamber, the cryogenic shrouds, the power supplies and the solar simulator lamp.
The axis count is four and the motor count is eight. Four motors drive Z, two drive X, one drives Y, and one drives the E axis, which is either a polymer pellet extruder or, with a NEMA 34 30:1 worm gearbox fitted, a rotary motion axis for a tool [8]. All motors are NEMA 34 driven by DM860I stepper drives. The linear axes are Nook ball screw DLK120 actuators in X and Y and non-back-driving DLT120 lead screw actuators in Z [8]. Linear accuracy is quoted at 0.033 percent, with repeatability of plus or minus 0.025 mm in X and Y; Z is given as lash-free on the grounds that the orientation of that axis makes backlash negligible, and no measured Z repeatability is published. Maximum velocity is 100 mm/s in X and Y and 25 mm/s in Z, at 1000 mm/s2 acceleration [8].
Control is deliberately conventional: a Bigtreetech Octopus V1.4 board with a Raspberry Pi 4 running MainsailOS, reachable over the local network, accepting g-code files or typed g-code [8]. That choice puts additive construction toolpaths, which are already g-code, directly onto the machine, and it means a campaign brings a toolpath rather than a control system. T-slot mounting runs along all axes for sensors and bracketry [8].
Dust tolerance is the design feature that separates ARGO from a laboratory gantry: the moving axes carry spring steel shielding bands over the carriage rails whose stated function is to prevent dust intrusion [8]. This is what allows the gantry to work over an open simulant bed rather than beside one.
Two build surfaces sit under it. The Universal Build Plate carries either a polyetherimide sheet on a 760 x 760 x 12.25 mm cast aluminum block, for conventional polymer printing, or a 12.5 mm regolith bed in the same frame [8]. Two Custom Heaters and Research silicone heaters of 450 W each, 340 x 720 mm, sit underneath and take the plate to 100 C in air or under vacuum, serving as both a build surface heater and a limited bakeout system that shortens warm-up after a cryogenic test. The separate 50 mm Regolith Bed is a deeper surface, 794 x 720 mm, with garolite thermal isolation underneath and forklift or hand lifting points, screeded flat with capture channels on all four sides [8].
Artemis Arena
Section titled “Artemis Arena”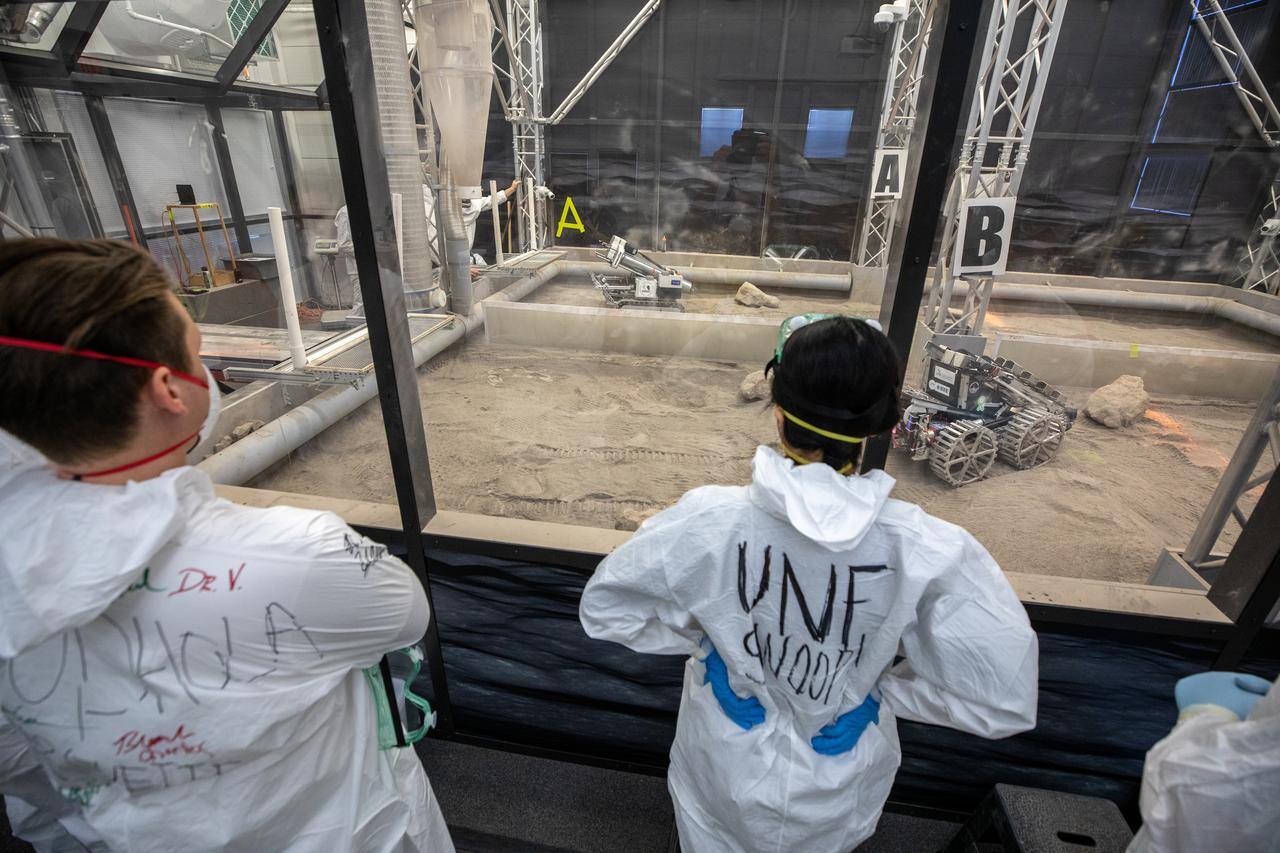
NASA/NASA KSC. Public domain (NASA / US government work).
| Parameter | Value |
|---|---|
| Working volume | About 6.8 x 5.0 m internally between the perimeter ducts, about 45 cm of simulant |
| Simulant or terrain | BP-1 about 45 cm deep, with about 2 cm gravel and larger rocks mixed in |
| Instrumentation | Perimeter dust suppression duct, 17 cm diameter |
Source: [11].
The Artemis Arena is a large enclosed simulant bin filled with about 45 cm of Black Point-1 crushed basalt over an internal footprint of roughly 6.8 by 5.0 m [11]. It began as the arena for the Lunabotics university robotic mining competition, which has run annually since 2010, and its obstacle layout is that competition’s terrain design offered as a facility [11][12]. Kennedy describes it as a testbed for external customers validating systems “in a simulated lunar mare environment” and states that it is open to industry, academia and government teams.
NASA/NASA KSC. Public domain (NASA / US government work).
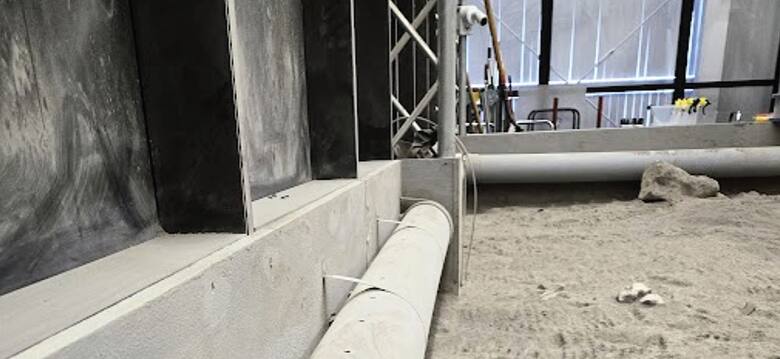
The arena is a rectangular bin with a hard boundary rather than an open floor: the quoted 6.8 by 5.0 m is measured between the ducts on the inside of the arena, not to the walls [11]. Those ducts are the dust suppression ventilation system, 17 cm in diameter, and they run the full perimeter, so the working footprint is set by the extraction plant [11][12].
Terrain is built rather than sculpted. The bed is about 45 cm of BP-1; gravel of about 2 cm and larger rocks are mixed in at random; an obstacle zone takes boulders of roughly 30 to 40 cm diameter at random heights and craters of varying shape no deeper or wider than 40 to 50 cm; and boulders may also appear in the excavation zone, within the same size bounds [11][12]. The stated design intent is that the obstacle field can be constructed so that reaching the excavation zone requires obstacle detection, mapping and navigation planning to find a slalom route. A central structural support column is a permanent hazard that must be avoided [11][12].
BP-1 is the choice that defines what the arena is good for. It is silt-sized washing waste from an aggregate quarry on the Black Point basalt flow in the San Francisco Volcanic Field, Arizona, selected as a geotechnical rather than a compositional simulant: the alkali content of the parent alkaline continental basalt is too high for compositional work, though its iron to magnesium ratio is mare-like and its geotechnical properties resemble NU-LHT-2M and Chenobi [13]. Measured on a common instrument against ten other simulants, BP-1 has a mean particle size of 198 um, D10 of 92.10 um, D50 of 228.91 um and D90 of 319.80 um, an aspect ratio of 0.654 and sphericity of 0.528, and contains nothing coarser than 2 mm by design [14]. The 2 cm gravel and the 30 to 40 cm boulders in the arena are therefore added material, not part of the simulant’s own grading.
The Lunabotics competition that shaped the arena also shaped its task. Teams design and build a remote controlled or autonomous excavator, operated from a remote mission control center, and the original task was to collect and deposit a minimum of 10 kg of lunar simulant within 15 minutes [12]. In later seasons the goal was changed to excavating a minimum of 1 kg of simulated icy regolith found under an overburden of regolith simulant, which is what puts the layered bed in the arena. The stated complexities are the abrasive character of the Black Point-1 simulant and the icy-regolith simulant, the weight and size limitations imposed on the robot, and the remote or autonomous control requirement [12]. The competition vehicle envelope and mass limit are not published.
The arena has no published instrumentation. Kennedy’s facility page describes the terrain, the obstacle rules and the dust extraction, and lists nothing that measures the article [11]. The rest of the laboratory carries a full geotechnical bench, high speed cameras with videographic analysis, a spectrum analyzer and a millimeter wave Doppler radar for dust ejecta velocity [7]. Soil state in the arena could be established with the tools used in the other bins, the pocket and cone penetrometers of the Big Bin campaigns [2], but neither is described as arena equipment.
Actuator test rig
Section titled “Actuator test rig”| Parameter | Value |
|---|---|
| Test article limits | Torque inputs above 300 Nm, with input and output feedthroughs |
| Vacuum | To 1 millitorr |
| Temperature | To 40 K |
| Instrumentation | Torque transducers for efficiency; real-time gear tooth decay measurement |
Source: [7].
Actuator testing is the least widely known of the laboratory’s capabilities and the most specific: vacuum to 1 millitorr, temperatures to 40 K, input and output feedthroughs, torque inputs above 300 Nm, efficiency measured through torque transducers, and real-time gear tooth decay measurement [7]. The laboratory also lists multiple cryogenic dusty environmental chambers alongside it, without published dimensions.
Soil mechanics and geotechnical bench
Section titled “Soil mechanics and geotechnical bench”| Parameter | Value |
|---|---|
| Working volume | Benchtop; specimen sizes not published [7] |
| Instrumentation | Proctor compactor, vibration table with relative density set, triaxial and direct shear cells |
The standing soil mechanics bench holds a proctor compactor, limit devices, a vibration table with relative density set, triaxial shear, direct shear, consolidation and permeation cells, a fine particle analyzer, sieves and shaker, a soil compressor, coring devices, hand-held testers, wet and dry sieving, a hydrometer test set, a drying oven, furnaces, a dehumidifier and microscopy [7]. It is what conditions and characterizes the beds between runs, and it is why a campaign in the bins can report a bulk density and a relative density rather than only a tool force.
Bevameter
Section titled “Bevameter”| Parameter | Value |
|---|---|
| Instrumentation | Interchangeable plates over a load cell, with an electromechanical linear actuator |
The laboratory operates a bevameter for pressure-sinkage measurement on BP-1 and on highlands simulants, built from bolted aluminum extrusion carrying an electromechanical linear actuator with interchangeable square and rectangular plates over a sandwiched load cell, logged from an Arduino. Plate dimensions, the bulk density range worked over and the pressure-sinkage results are not published.
Plume erosion and dust extinction diagnostic
Section titled “Plume erosion and dust extinction diagnostic”| Parameter | Value |
|---|---|
| Working volume | Laser path about 7.9 m across the main bin |
| Illumination | 33 laser array against white targets, recorded on high speed HD video |
| Instrumentation | Laser plus digital camera, in extinction or side-scatter mode |
Source: [1].
Dust density in the bin is measured optically. The plume erosion sensor is a laser plus digital camera against a white target, operated either as a single spot whose brightness attenuates with optical extinction, or in side-scatter where the camera images the beam entering the cloud. The extinction measurement returns the product of the second moment of the particle size distribution and the extinction efficiency, which for particles above 1 micron is approximately 2, so a mean particle size must be assumed to recover number density [1]. The single-sensor method was developed in the JSC-1A bin and then scaled up in the main bin to an array of 33 lasers illuminating multiple targets, recorded on high speed HD cameras, over a laser path of about 7.9 m across the bin.
Plume surface interaction rig
Section titled “Plume surface interaction rig”| Parameter | Value |
|---|---|
| Working volume | 150 kg simulant bin with a transparent side plate, inside a vacuum chamber |
| Vacuum | Prepared and fired under vacuum; pressure not published as a figure |
| Instrumentation | Vane shear for prepared-bed characterization; imaging through the transparent side plate |
Source: [4].
A 150 kg simulant bin is prepared under vacuum for firings of a Mach 5.3, 500 K gaseous nitrogen jet, with a transparent side plate so crater evolution can be imaged [4]. The laboratory’s wider dust and plume diagnostics are the rocket plume testers, high speed video with videographic analysis, a 3.6 GHz spectrum analyzer and a millimeter wave Doppler radar used to estimate dust ejecta velocity, alongside a dust hood and a sandblast hood [7].
Fabrication and manipulation hardware
Section titled “Fabrication and manipulation hardware”| Parameter | Value |
|---|---|
| Test article limits | A Fanuc industrial robot, a UR10 and a Kuka arm are available [7] |
| Instrumentation | Workstations running PFC2D, PFC3D, EDEM, COMSOL, Mathematica, LabVIEW and Fortran |
Manipulation and fabrication hardware includes a Fanuc industrial robot, a UR10 arm and a Kuka industrial arm, three Lulzbot and three Ultimaker printers, a CNC router, two CNC mills, a lathe and band saws, with workstations running PFC2D, PFC3D, EDEM, COMSOL, Mathematica, LabVIEW and custom Fortran for the discrete element work the bins feed [7]. The arms are the manipulation route for work that does not need vacuum, where the ARGO gantry is used when the chamber is the reason for the test.
Instrumentation
Section titled “Instrumentation”Position ground truth in the main bin is an OptiTrack system of six wall-mounted cameras tracking an infrared marker on the article, with positional error below 0.3 mm [3]. Slip is computed as the difference between commanded ideal rolling distance and OptiTrack distance [3].
Force instrumentation is chosen per campaign. Wheel drawbar pull used an Interface SM-250 transducer with a plus or minus 150 lbf range and 0.03 percent full-scale nonlinearity at 100 Hz [3]. Plate compaction used two ATO LCMA-DYDW-005 triaxial cells of 500 N each, summed for a 0 to 1000 N range corresponding to 0 to 92.6 kPa under the tool plate, with a Futek LCM300 single-axis cell substituted for the in-vacuum configuration where the ARGO gantry provided the motion, and a 1.25 micron linear optical encoder [2].
Soil state is measured with three hand tools [2]. A 60 mm diameter, 25 mm deep thin-walled core sampler is pressed in and weighed for bulk density. A Humboldt HS-4210 cone penetrometer with a 60 degree, 1.5 cm2 cone is lowered at 1 to 2 cm/s, with readings called at 51, 76, 102, 127, 152, 178 and 203 mm and averaged into upper, middle and lower zones [2]. A Humboldt H-4205 pocket penetrometer takes a 20 mm foot for compacted ground and a custom 60 mm foot for uncompacted ground, both 15 mm thick and pressed until flush. Vane shear is used where the prepared bed’s shear strength is the controlled quantity [4].
Inside the chamber the instrument that distinguishes ASSIST from a plain thermal vacuum chamber is the Inficon MPH200M residual gas analyzer, to 200 AMU with an electron multiplier, because it is plumbed to its own turbo and roughing pumps and can therefore run while the chamber itself is only at rough vacuum, below 10 torr, and be isolated without breaking the chamber [8]. Outgassing, vacuum-based chemical processing and environmental composition monitoring are the three stated uses, and all three are in-test measurements rather than post-test ones.
Optical access to the chamber is by two 0.5 x 0.5 m door viewports and a 25.4 cm fused silica port on top used for the solar simulator beam [8]. A window-to-conflat adapter trades one door window for a 4.5 in zinc selenide port, so a FLIR A35-FOV45 can read temperatures inside over -25 to 100 C and -40 to 550 C, to plus or minus 5 percent of reading. A 4K Logitech Brio sits inside on a USB 3.0 feedthrough [8]. Thermocouple and load cell logging is provided through the ARGO gantry’s National Instruments four-card data acquisition system, so a test not using the gantry brings its own instrumentation. For the molten regolith electrolysis campaign the facility instrumentation was extended by the article’s own diagnostics: the Volatile Monitoring and Oxygen Measurement System extracted the gas volatiles from the reactor and combined a 0.1 ppm low concentration oxygen sensor, a 95 percent high concentration oxygen sensor, an Inficon Transpector CPM200M residual gas analyzer and flow rate and temperature measurement, which is what quantified the oxygen produced [9].
ARGO’s own positional ground truth is mechanical rather than optical: there is no motion capture volume inside the chamber, accuracy is the 0.033 percent quoted for the linear rail mechanism and repeatability is plus or minus 0.025 mm in X and Y, which across a 754 mm axis is about 0.25 mm [8].
What it does not reproduce
Section titled “What it does not reproduce”Gravity. The bins are 1 g facilities [8][11]. Excavation reaction forces, bearing capacity and sinkage under a given plate pressure are all gravity-dependent, and neither the chamber nor the arena has any offload at all [8][11].
Regolith. BP-1 is a mechanical simulant, crushed from a terrestrial basalt, selected because its particle size distribution falls within one standard deviation of Apollo returned soil [3]. It is not compositionally or texturally lunar, and its alkali content is too high for compositional work [13]. LHS-1 highlands simulant is used where a highlands analogue is needed [2]. The arena is described as a simulated lunar mare environment while the Artemis landing region is highlands [11].
Bed repeatability. The operators state plainly that preparing the test area with precision is challenging and time consuming, and that preparation must be done with care to create consistent conditions [2]. Consequences are documented rather than asserted: raking to level slightly increases surface density, and grading with the test stand increases it again [2]. Achievable initial states are bounded, with relative densities below about 48 percent not practical to create. In wheel testing, the article’s own tracks have to be filled in and the bed re-leveled between every run [3]. No relative density preparation or measurement procedure is published for the arena at all, so a bin worked over by a season of excavators has a density history rather than a prepared state [11][2].
Vacuum with a granular article inside. Simulant erupts during pumpdown as trapped interstitial gas escapes, disturbing the prepared surface. Any geotechnical characterization performed before evacuation is therefore invalid at test time, and vacuum-specific preparation procedures exist for that reason. The stated preference is for a system that can fill the test bin with simulant inside the chamber and under vacuum, which does not yet exist at large scale [4]. In compaction work the workaround was a final leveling pass performed by the tool itself under vacuum before the test began [2].
Base pressure with the article working. The published chamber pressures fall into a hierarchy that a specification sheet flattens. Empty and pumped, 3.5 x 10^-6 torr; with the ARGO gantry installed, 1 x 10^-5 torr [8]. During cryogenic additive construction, 4 x 10^-4 torr or lower, with the operators stating that gauge limitations at the time prevented verifying anything below that [8]. During regolith electrolysis with a 6.5 L/min gaseous nitrogen purge running to keep the roughing pump out of a 100 percent oxygen environment, and with the turbomolecular pump not yet fitted, 2 to 6 torr. The chamber’s lowest published pressure and the pressure at which its most cited campaign ran differ by about six orders of magnitude, and any in-situ resource utilization process that liberates oxygen faces the same purge constraint.
Hot articles without shielding. The elastomeric flange seals cap the chamber wall at 150 C [8]. The thermal analysis supporting the molten regolith electrolysis test was written specifically to identify protection options to hold the internal walls below 150 C, and the protection it modeled includes an aluminum radiative shield fastened to the water-cooled walls, a refractory brick base plate under the reactor, and a fan cooling the chamber floor from outside because the floor is not water cooled [10]. The predicted result after 37.5 hours with a 1600 C melt inside was 55 C maximum on the borosilicate windows and 49 C on the door, with the floor rising considerably more than the three water-cooled walls [10].
A characterized cold volume. The Mini-Shroud’s cooling rate is published, three E-type thermocouples clamped to its aluminum body reaching below -200 C in about two hours, with the note that the spread between the wall thermocouples and the cryocooler contact thermocouple would narrow given more cooling time [8]. The Mega-Shroud, the shroud large enough to hold a rover-scale article, is stated as not fully characterized thermally, with characterization listed as future work [8].
The gantry’s own operating temperature, speed and payload. ARGO is rated -10 to 80 C while the environment it works in reaches below -200 C at the shroud and 100 C at the heated bed, and the operators are explicit that the -10 to 80 C figure is the linear actuator manufacturer’s recommended range rather than a measured limit [8]. A cryogenic campaign is therefore one in which the tool is cold and the machine moving it is not. Maximum velocity is 100 mm/s in X and Y and 25 mm/s in Z, so a process depending on tool speed above those rates cannot be reproduced, and payload stops at 90 kg [8]. Dust tolerance is by spring steel shielding bands over the carriage rails, not by sealed or dust-immune actuators, and nothing is published on ingress after a given number of cycles or on whether the bands hold at cryogenic temperature [8].
Bulk terrain inside the chamber. The chamber’s simulant beds are 12.5 mm and 50 mm deep over an area under 0.6 m2 [8]. It is a chamber for a tool, a reactor or an end effector interacting with a prepared surface, not for a vehicle driving across terrain; that work is done at ambient pressure in the bins and the arena [11].
Load measurement at the extremes of range. In 7 kPa spot compaction tests the measured peak pressure sometimes read below the known static pressure applied by dead weight, indicating substantial uncertainty at the low end of the 0 to 92.6 kPa range [2]. At 70 kPa static load the cells returned load in all three axes and no reliable peak, attributed to flexure or preload in the assembly, with no confident failure mode identified; those tests were reported as assumed static pressure instead of measured [2].
Bin edges, mixed simulants and hand measurement. Shear strength varies as the wall of the simulant bin is approached, so test locations have to be chosen to account for it, and high cone penetrometer readings in the 152 to 203 mm zone are attributed to the bottom of the prepared region rather than to the soil [2][4]. Running two simulants in one bin requires physical separation, the LHS-1 container being set in a tarp-lined pit to keep it out of the BP-1. The cone penetrometer is hand-operated and carries a relatively high uncertainty, which limits what can be concluded from small data sets [2].
A lunar terrain distribution in the arena. Obstacle sizes are bounded at both ends by rule: boulders 30 to 40 cm, craters no deeper or wider than 40 to 50 cm [11]. The bounds are those of a competition course rather than a size-frequency distribution fitted to lunar observation, and nothing above 50 cm is encountered. Two fixed obstacles have no lunar counterpart, the central structural support column and the 17 cm perimeter duct, so an autonomy stack evaluated there meets one smooth cylinder and one continuous rail around the workspace boundary [11]. At 6.8 by 5.0 m the arena also holds a traverse of only a few vehicle lengths; navigation over distance is done outdoors at the Surface Autonomy Test Site [7].
Vacuum, temperature and illumination in the arena. None of the three is provided [11]. An autonomy or mobility result from the arena is an ambient-air, room-temperature, room-lit result, and no instrumentation is published there, so what the arena establishes about a test article is whatever the article and its operators record, plus the mass of simulant moved [11].
Campaigns run there
Section titled “Campaigns run there”IPEx wheel configuration testing, published 2024. Ten wheel configurations, built from four cleat sets and six grouser sets out of 24 possible combinations, were run on RASSOR 2.0 as an IPEx surrogate in the main bin [3]. Variables were square against round wheel shape, solid against perforated cleats, cleat spacing, grouser height and grouser spacing. Four test types were run: circle driving at one linear and three angular speeds, straight driving at three linear speeds, a 20 degree slope, and drawbar pull with weights incrementally added to a towed sled [3]. Slip came from OptiTrack, power from per-wheel motor current. Result: no configuration dominated. Taller square grousers slip less but draw more power; cleat perforation had no strong effect on either slip or power, so perforated cleats are preferred on mass grounds; wheel 5, with short rounded grousers, was taken as the baseline [3]. The bin allowed continuous drives over 8 m, longer than the runs in the prior wheel literature [3].
PACT vibratory plate compaction, published 2025. The Planetary Automated Compaction Tool was run on the Excavation Test Stand in the main bin against BP-1, and in a trapezoidal container against LHS-1, in both spot and raster motion, at 7 and 70 kPa static pressure and at 0, 45 and 71 Hz vibration [2]. Measured peak pressures were 3.45 to 3.9 kPa for raster at zero static pressure and 6.8 to 11.3 kPa for spot at 7 kPa static. Findings: 7 kPa static plus roughly 3.5 to 4.0 kPa of vibratory force reaches 80 percent relative density at the surface; contact time beyond 30 seconds gives diminishing returns at 71 Hz; 71 Hz compacts subsurface better than 45 Hz; raster without static pressure is less effective than spot; BP-1 and LHS-1 behave similarly under plate compaction [2]. A 9.3 kPa applied pressure took BP-1 from 60 to 99 percent relative density and LHS-1 from 54 to 84 percent [2].
LHS-1 compaction, ambient against vacuum. The same tool and container were run in ASSIST at 8 x 10^-3 Torr or lower using the ARGO gantry for motion, with compaction pressure verified by a Futek LCM300 load cell between tool and gantry, and the results compared against the ambient runs [2]. Ambient and vacuum compaction densities were comparable, with the vacuum condition showing slightly different behavior; core sampling in vacuum was performed after venting [2].
Plume surface interaction simulant preparation, 2022. A 150 kg simulant bin was prepared under vacuum for firings of a Mach 5.3, 500 K gaseous nitrogen jet, with a transparent side plate so crater evolution could be imaged [4]. The campaign is the source of the vacuum eruption finding and of the vane shear preparation procedure, and it concluded that consistent large-scale vacuum bed preparation needs a filling system that works inside the evacuated chamber [4].
Reinforcement learning trenching, 2021. Under the Intelligent Capabilities Enhanced RASSOR project, autonomous trenching controllers were learned by reinforcement learning in two reduced-order simulations, a 2D excavation simulation used to select parameters and a 3D simulation built on a game physics engine with simplified soil interaction and dynamically parameterized robot models [5]. The learned excavation routines exceeded the excavation efficiency of RASSOR’s existing control and teleoperation-based methods in simulation, the work explicitly targeting transfer to hardware in the laboratory’s regolith bin [5].
IPEx camera thermal vacuum, published 2024. IPEx flight cameras were run through thermal vacuum in the ASSIST chamber [6].
Gaseous Lunar Oxygen from Regolith Electrolysis, before 2021. A cold-wall molten regolith electrolysis reactor, in which the melt is contained by surrounding cold granular regolith rather than by the reactor housing, was run in ASSIST powered by the 15 kW supply for electrolysis and the 10 kW induction coil for melt heating [8]. The turbomolecular pump was not yet installed and a 6.5 L/min gaseous nitrogen purge was running, so chamber pressure during the test was 2 to 6 torr. Output composition was measured with the residual gas analyzer and flow rate with a volumetric flow meter on the roughing pump exhaust. The reactor produced oxygen [8].
Relevant Environment Additive Construction Technology. Additive construction with regolith-polymer composite formulations, printed by the ARGO gantry inside the ASSIST chamber using the Mini-Shroud [8]. Shroud temperature was below -200 C with the build plate below -90 C, and the chamber held 4 x 10^-4 torr or lower, the limit of the gauges then fitted. Data collection combined the gantry’s thermocouple acquisition, 4K 60 frame per second video and the FLIR camera through the door adapter [8].
Moon-to-Mars Planetary Autonomous Construction Technology site preparation tool. A multi-use lunar site preparation tool tested on the ARGO gantry with the rotary E-axis and the heated regolith bin, at pressures down to 1 x 10^-5 torr [8].
Molten regolith electrolysis with Lunar Resources, late 2024. The LR-1 reactor built by Lunar Resources was run in ASSIST for five days on 25 kg of LHT-1G simulant, in a chamber retrofitted for the heat [9]. Regolith was raised to about 1573 K and held molten by Joule heating, electrolysis was sustained for 9 hours, and the average oxygen production rate was 0.07 kg/hr, the largest reactor known to have demonstrated direct quantified oxygen production from regolith. Gaseous products were measured during electrolysis by the Volatile Monitoring and Oxygen Measurement System. A core sample about 3 in in diameter and 4 in tall, carrying the anode, the solidified melt and the metal cathode, was recovered from the cooled reactor and examined by computed tomography for porosity and density, and by X-ray diffraction, scanning electron microscopy and energy dispersive spectroscopy [9]. The supporting thermal and computational fluid dynamics model was built in COMSOL Multiphysics with 787,188 tetrahedral elements, covering a heating phase to 1400 C followed by an electrolysis phase at 1600 C over a 37.5 hour test, and was used during the test to compare measured against simulated temperatures and flag non-nominal conditions [10].
Lunabotics robotic mining competition, 2010 to 2019. Ten annual competitions in the arena, drawing over 50 university teams a year [12]. The published output is a taxonomy of excavation and regolith transport mechanisms across those designs, compiled by the Kennedy organizers with Michigan Technological University, Caterpillar and the Florida Space Institute, and intended as design information for later competitors [12]. Robots were teleoperated or run autonomously from a remote mission control center. The Swamp Works excavator line, RASSOR 1.0 and 2.0 and IPEx, was developed by the same organization over the same period [12], but no published account places a specific RASSOR or IPEx test run in the arena rather than in the bins.
Compaction tool development. MEERCAT, the Multifunctional End Effector for Regolith Construction, Acquisition and Transfer, is a robotic arm end effector developed in the laboratory whose capabilities span excavation, trenching, regolith size screening, compaction and geotechnical property measurement. Its compaction function was developed further under the NASA Tipping Point project Mason, led by Redwire Space with the laboratory contracted for the compaction system, under the name Planetary Automated Compaction Tool [2].
Dust density measurement in the bin, 2016. The plume erosion sensor was developed in the JSC-1A bin and scaled to a 33 laser array in the main bin, to quantify how degraded lighting and airborne dust affect computer vision and operator perception, on the stated grounds that current space telerobotic systems are only operated in bright, dust-free conditions and that telerobotic performance under dust is poorly understood [1].
References
- Lane, J. E., Mantovani, J., Mueller, R., Nugent, M., Nick, A., Schuler, J. and Townsend, I. I. (2016). Optical Extinction Measurements of Dust Density in the GMRO Regolith Test Bin
. Earth and Space, 20160005055. Source
BibTeX
@inproceedings{lane2016optical, title = {Optical Extinction Measurements of Dust Density in the GMRO Regolith Test Bin}, author = {Lane, John E. and Mantovani, J. and Mueller, R. and Nugent, M. and Nick, A. and Schuler, J. and Townsend, Ivan I.}, booktitle = {Earth and Space}, number = {20160005055}, pages = {36-47}, institution = {NASA}, year = {2016}, doi = {10.1061/9780784479971.005}, abstract = {A regolith simulant test bin was constructed and completed in the Granular Mechanics and Regolith Operations (GMRO) Lab in 2013. This planetary regolith test bed (PRTB) is a 64 m2 × 1 m deep test bin housed in a climate-controlled facility and contains 120 MT of lunar-regolith simulant, called Black Point-1 or BP-1, from Black Point, AZ. One of the current uses of the test bin is to study the effects of difficult lighting and dust conditions on telerobotic perception systems to better assess and refine regolith operations for asteroid, Mars, and polar lunar missions. Low illumination and low angle of incidence lighting pose significant problems to computer vision and human perception. Levitated dust on asteroids interferes with imaging and degrades depth perception. Dust storms on Mars pose a significant problem. Due to these factors, the likely performance of telerobotics is poorly understood for future missions. Current space telerobotic systems are only operated in bright lighting and dust-free conditions. This technology development testing will identify: (1) the impact of degraded lighting and environmental dust on computer vision and operator perception, (2) potential methods and procedures for mitigating these impacts, (3) requirements for telerobotic perception systems for asteroid capture, Mars dust storms, and lunar regolith ISRU missions.} } - Bell, E. A., Kemmerer, B. W., Gelino, N. J., Sibille, L., Holmgren, G. M., Flowers, P. F. and Rao-Aourpally, V. (2025). Vibratory Plate Compaction of BP-1 and LHS-1 Utilizing the Planetary Automated Compaction Tool (PACT)
. NASA, 20250005172. Source
BibTeX
@techreport{bell2025vibratory, title = {Vibratory Plate Compaction of BP-1 and LHS-1 Utilizing the Planetary Automated Compaction Tool (PACT)}, author = {Bell, E. A. and Kemmerer, B. W. and Gelino, Nathan J. and Sibille, Laurent and Holmgren, G. M. and Flowers, P. F. and Rao-Aourpally, V.}, number = {20250005172}, institution = {NASA}, year = {2025}, url = {https://ntrs.nasa.gov/citations/20250005172}, abstract = {The Multifunctional End Effector for Regolith Construction, Acquisition, and Transfer (MEERCAT) is a robotic arm end effector developed by the Swamp Works Granular Mechanics and Regolith Operations (GMRO) lab [1]. This system has several capabilities including excavation, trenching, regolith size screening, compaction, and geotechnical property measurement. The NASA Tipping Point Project, Mason, led by Redwire Space, in partnership with the Swamp Works GMRO lab, has continued development and refinement of the PACT system’s compaction capabilities, specifically, under the new moniker Planetary Automated Compaction Tool (PACT). A test campaign in ambient laboratory conditions was conducted using Black Point-1 (BP-1) and Lunar Highlands-1 (LHS-1) simulants in the GMRO’s Big Bin test facility utilizing the Excavation Test Stand (ETS) 2-axis gantry. Along with this work a correlation curve was developed to estimate bulk surface compaction based on surface pocket penetrometer readings of penetration force into simulant. The tests revealed the PACT system to be capable of achieving 80% relative density (%RD) in BP-1 and LHS-1 using a dual-mass excentric mass motor. Testing showed that the Spot compaction method was more capable of compaction at depth (below 51 mm) than the Raster method. Several other conclusions were made including that higher static compaction pressure improved compaction at depth, and that longer surface contact times provided diminishing returns on compaction performance. A correlation between the ambient testing in LHS-1 performed as part of this test campaign and previous work performed in-vacuum conditions using LHS-1 is also shown over a test sample set.} } - Zhang, L., Schuler, J., Dokos, A., Xu, Y., Bell, E. and Muller, T. (2024). ISRU Pilot Excavator Wheel Testing in Lunar Regolith Simulant
. Earth and Space, 20240001016. Source
BibTeX
@inproceedings{zhang2024isru, title = {ISRU Pilot Excavator Wheel Testing in Lunar Regolith Simulant}, author = {Zhang, Liz and Schuler, Jason and Dokos, Adam and Xu, Yinan and Bell, Evan and Muller, Thomas}, booktitle = {Earth and Space}, number = {20240001016}, pages = {173-187}, institution = {NASA}, year = {2024}, doi = {10.1061/9780784485736.016}, abstract = {The ISRU Pilot Excavator (IPEx), is a robotic excavator funded by NASA’s Space Technology Mission Directorate (STMD). The Concept of Operations for IPEx involves the robot driving on the lunar surface up to 70 km at a speed of up to 30 cm/s. As such, it is critical to the mission’s success to optimize the design of the wheels for performance in lunar conditions, specifically in lunar regolith. To achieve this, an array of tests was completed to observe the effects of various wheel design choices on the driving performance of the wheels in lunar regolith simulant. In order to facilitate testing, we designed a 12 in. dia. configurable wheel to allow for interchangeability between various wheel formations. Two types of wheel parts were designed to be swapped: cleats, which form the tread of the wheel; and grousers, which protrude from the treads. The test variables that we considered were as follows: square versus round wheel shape, solid versus perforated cleats, cleat spacing, grouser height, and grouser spacing. By combining different settings of each of these test variables, 10 discrete wheel designs were created and tested. The configurable test wheels were mounted on the Regolith Advanced Surface Systems Operations Robot (RASSOR) developed at NASA’s Kennedy Space Center. In our experiments, the robot was driven at a controlled speed across a prepared surface of BP-1 lunar regolith simulant. Four types of tests were conducted: circle driving, straight driving, slope driving, and drawbar pull. The driving tests were chosen to mimic a variety of conditions in which IPEx may be expected to operate, and the drawbar pull test was chosen to provide a standard of comparison with existing wheel design literature. The circle and straight driving tests were each performed at different levels: for the circle driving test, the robot was driven at a constant linear speed and three different angular speeds, while for the straight driving test, the robot was driven at three different linear speeds. The data collected from these tests included the power usage from each of the wheels, measurements of the tread patterns left in the regolith surface, and the amount of slip the wheels experienced, which was calculated using data from an OptiTrack motion capture system. From the results of these experiments, we found that certain test variables were more significant than others in determining performance for each type of test, and no single wheel design clearly outperformed the others in all areas. The details of our findings will be discussed further in this paper. These data will be utilized to inform the design of the wheels for IPEx and can provide a basis for the design of wheels for future lunar terrain vehicles.} } - Mantovani, J., Langton, A., Kemmerer, B., Atkins, A. and Batcheldor, D. (2022). Regolith Simulant Preparation and Geotechnical Characterization for Plume Surface Interaction Testing
. NASA, 20220013110. Source
BibTeX
@techreport{mantovani2022regolith, title = {Regolith Simulant Preparation and Geotechnical Characterization for Plume Surface Interaction Testing}, author = {Mantovani, James and Langton, Austin and Kemmerer, Beverly and Atkins, Austin and Batcheldor, Daniel}, number = {20220013110}, institution = {NASA}, year = {2022}, url = {https://ntrs.nasa.gov/citations/20220013110}, abstract = {Descent engine plumes interact with the lunar surface and accelerate regolith particles to potentially high velocities. These ejecta create risks to surface assets that have yet to be fully assessed. To better understand these risks, plume surface interactions can be simulated on the ground by firing a test engine plume into a bin of lunar regolith simulant under vacuum conditions. The dynamics of the resultant ejecta can then be recorded. In this technical memorandum we discuss the processes used in preparing a 150 kg bin of lunar regolith simulant for plume surface interaction ground tests under vacuum conditions for the NASA STMD Plume Surface Interaction project. We present our approach to mitigating regolith simulant eruptions during pump-down, the methods used to fill and reset the regolith simulant bin for each test, and the techniques used to characterize the consistency of regolith simulant geotechnical properties before each new firing. The challenges of preparing a regolith simulant test bin below an ambient pressure of one atmosphere, particularly on the large scale, could largely be overcome with a system that could fill the test bin with simulant inside the chamber and under vacuum conditions.} } - Cloud, J. M., Nieves, R. J., Duke, A. K., Muller, T. J., Janmohamed, N. A., Buckles, B. C. and DuPuis, M. A. (2021). Towards Autonomous Lunar Resource Excavation via Deep Reinforcement Learning
. ASCEND, 20210022218. Source
BibTeX
@inproceedings{cloud2021autonomous, title = {Towards Autonomous Lunar Resource Excavation via Deep Reinforcement Learning}, author = {Cloud, Joseph M. and Nieves, Rolando J. and Duke, Adam K. and Muller, Thomas J. and Janmohamed, Nashir A. and Buckles, Brad C. and DuPuis, Michael A.}, booktitle = {ASCEND}, number = {20210022218}, publisher = {American Institute of Aeronautics and Astronautics}, institution = {NASA}, address = {Las Vegas, Nevada}, year = {2021}, doi = {10.2514/6.2021-4217}, abstract = {View Video Presentation: https://doi.org/10.2514/6.2021-4217.vid To support sustainable infrastructure on the Moon, NASA needs to leverage lunar resources for in-situ processing and construction. NASA’s Regolith Advanced Surface Systems Operations Robot (RASSOR) is principally designed to mine and deliver regolith for these tasks. To reliably perform these operations on the lunar surface, RASSOR's sensors and control systems need to be robust and maximize information extracted from a reduced sensor payload. Herein, we present our findings from the Intelligent Capabilities Enhanced RASSOR project. We created reduced-order simulation environments in which we applied reinforcement learning algorithms to learn autonomous trenching controllers and produced state estimation architectures. We developed two simulations: a 2D excavation simulation used to facilitate parameter selection, and a 3D simulation developed using a game physics engine to simulate simplified soil interactions and incorporate robotic agents parameterized by dynamic models. Within these simulations, we learned autonomous excavation routines that exceed excavation efficiency measures as compared against RASSOR's existing control and teleoperation-based methods.} } - Schuler, J. M., Smith, J. D., Nick, A. J., Buckles, B. C., Dyas, J. E., Ortega, V. V., Cloud, J. M., Dokos, A. G., Zhang, E. L., Wang, J. J., Baron, M. A., Muller, T. J., Clark, C. J. and Howe, M. W. (2024). ISRU Pilot Excavator (IPEx) Technology Readiness Level 5 Design Overview
. AIAA AVIATION Forum and ASCEND, 20240008162. Source
BibTeX
@inproceedings{schuler2024isru, title = {ISRU Pilot Excavator (IPEx) Technology Readiness Level 5 Design Overview}, author = {Schuler, Jason M. and Smith, Jonathan D. and Nick, Andrew J. and Buckles, Bradley C. and Dyas, Jeffrey E. and Ortega, Victoria V. and Cloud, Joseph M. and Dokos, Adam G. and Zhang, Elizabeth L. and Wang, Jerry J. and Baron, Michael A. and Muller, Thomas J. and Clark, Casey J. and Howe, Musashi W.}, booktitle = {AIAA AVIATION Forum and ASCEND}, number = {20240008162}, institution = {NASA}, year = {2024}, doi = {10.2514/6.2024-4890}, abstract = {This paper details the mechanical and mechatronic design of the Technology Readiness Level (TRL)-5 In-Situ Resource Utilization (ISRU) Pilot Excavator (IPEx). IPEx is a robotic excavator designed for a technology demonstration of regolith mining in the lunar south pole region. The novel design uses pairs of counter-acting excavation tools called bucket drums, that dig at the same time in opposing directions to reduce the reaction force needed, thereby enabling mining with a small, low-mass, robotic system. IPEx builds on the prior work of the Regolith Advanced Surface Systems Operations Robot (RASSOR), which is the TRL-4 implementation of this concept. The TRL-5 IPEx subsystems that are discussed in this paper include: Regolith Delivery Subsystem (RDS), Mobility Subsystem (MS), Cameras and Dust Mitigation Subsystem (CDMS), and Thermal Control Subsystem (TCS). Each subsystem is described in detail with rationale for design selections. Dust tolerance is a key feature for IPEx, and this paper details a thermal control system with an actuated radiator cover and phase change material as well as camera modules with removable electrodynamic dust shields (EDS). Additional components such as actuators, wheels, and bucket drums are discussed in detail. Due to their complexity, the avionics and software subsystems will be discussed in a separate publication.} } - NASA Kennedy Space Center. (2024). Granular Mechanics and Regolith Operations (GMRO). public.ksc.nasa.gov/partnerships/capabilities-and-testing/testing-and...
BibTeX
@misc{ksc2024granular, title = {Granular Mechanics and Regolith Operations (GMRO)}, author = {{NASA Kennedy Space Center}}, organization = {public.ksc.nasa.gov}, year = {2024}, url = {https://public.ksc.nasa.gov/partnerships/capabilities-and-testing/testing-and-labs/granular-mechanics-and-regolith-operations-gmro/} } - NASA Kennedy Space Center. (2025). Advanced Regolith Ground Operations (ARGO) Test Bed and the ASSIST Chamber. public.ksc.nasa.gov/partnerships/advanced-regolith-ground-operations-...
BibTeX
@misc{ksc2025advanced, title = {Advanced Regolith Ground Operations (ARGO) Test Bed and the ASSIST Chamber}, author = {{NASA Kennedy Space Center}}, organization = {public.ksc.nasa.gov}, year = {2025}, url = {https://public.ksc.nasa.gov/partnerships/advanced-regolith-ground-operations-argo-test-bed-a-robotic-excavation-and-construction-test-facility-with-simulated-lunar-environments/} } - Toro Medina, J. A., Meier, A., Shah, M., Bell, E., Essumang, D., Olson, J. A. and Sibille, L. (2026). Large-scale demonstration of molten regolith electrolysis for oxygen production in a relevant environment
. International Conference on Environmental Systems, ICES-2026-300. Source
BibTeX
@inproceedings{toromedina2026large, title = {Large-scale demonstration of molten regolith electrolysis for oxygen production in a relevant environment}, author = {Toro Medina, Jaime A. and Meier, Annie and Shah, Malay and Bell, Evan and Essumang, Deborah and Olson, Joel A. and Sibille, Laurent}, booktitle = {International Conference on Environmental Systems}, number = {ICES-2026-300}, address = {Rio Grande, Puerto Rico}, year = {2026}, doi = {10.32865/2346/108973}, abstract = {In late 2024, Kennedy Space Center (KSC), in collaboration with Lunar Resources Inc., conducted a large-scale demonstration of oxygen extraction from lunar regolith simulant using Molten Regolith Electrolysis (MRE). The experiment featured the LR-1 reactor, developed by Lunar Resources Inc., which processed 25 kg of regolith simulant and achieved an average oxygen production rate of 0.07 kg/hr under vacuum conditions. The electrochemical process was sustained for 9 hours, during which the regolith was maintained in a molten state, enabling continuous electrolysis. The reactor performed its functionalities inside the Atmospherically Sealed Simulator for In-situ System Testing (ASSIST) retrofitted to provide relevant environment conditions to the experiment while exposed to high temperatures. A custom-built Volatile Materials and Oxygen Measurement System (VMOMS) provided real-time monitoring and characterization of gas production throughout the experiment. Post-test analysis included sampling the reduced regolith to assess compositional changes. The experiment also validated that the process of Joule-heating of molten regolith could maintain the high-temperature regime necessary for sustained electrolysis. This demonstration marks a significant step toward maturing critical in-situ resource utilization (ISRU) technologies that support long-duration human presence on the Moon. The results and findings from this test will be detailed in this paper.} } - Sibille, L., Dziedzic, W. and Bell, E. A. (2024). A Transient Multiphysics Thermal/CFD Simulation Analysis of a Molten Regolith Electrolysis Reactor within a Thermal Vacuum Chamber
. Thermal and Fluids Analysis Workshop, TFAWS2024-ID-04. Source
BibTeX
@inproceedings{sibille2024transient, title = {A Transient Multiphysics Thermal/CFD Simulation Analysis of a Molten Regolith Electrolysis Reactor within a Thermal Vacuum Chamber}, author = {Sibille, Laurent and Dziedzic, William and Bell, Evan A.}, booktitle = {Thermal and Fluids Analysis Workshop}, number = {TFAWS2024-ID-04}, address = {Cleveland, Ohio}, year = {2024}, url = {https://tfaws.nasa.gov/wp-content/uploads/TFAWS2024-ID-04_Paper.pdf} } - NASA Kennedy Space Center. (2025). Artemis Arena. public.ksc.nasa.gov/partnerships/artemis-arena
BibTeX
@misc{ksc2025artemis, title = {Artemis Arena}, author = {{NASA Kennedy Space Center}}, organization = {public.ksc.nasa.gov}, year = {2025}, url = {https://public.ksc.nasa.gov/partnerships/artemis-arena/} } - Mueller, R. P., van Susante, P., Reiners, E. and Metzger, P. T. (2021). NASA Lunabotics Robotic Mining Competition 10th Anniversary (2010-2019): Taxonomy and Technology Review
. Earth and Space : Space Exploration, Utilization, Engineering, and Construction in Extreme Environments, 20210013143. Source
BibTeX
@inproceedings{mueller2021lunabotics, title = {NASA Lunabotics Robotic Mining Competition 10th Anniversary (2010-2019): Taxonomy and Technology Review}, author = {Mueller, Robert P. and van Susante, Paul and Reiners, Eric and Metzger, Philip T.}, booktitle = {Earth and Space : Space Exploration, Utilization, Engineering, and Construction in Extreme Environments}, number = {20210013143}, pages = {497-510}, organization = {American Society of Civil Engineers}, year = {2021}, doi = {10.1061/9780784483374.047}, abstract = {Space mining for resources such as water ice and regolith, which contain many elements in the form of metals, minerals, volatiles, and other compounds, is a necessary step for in-situ space resource utilization (ISRU). One of the primary goals is to extract propellants from the regolith and water ice, such as oxygen and hydrogen which could then be used for in-space transportation. In addition, the space mining system can be used for various construction tasks that can benefit human and robotic exploration as well as scientific investigations based on excavated exposed topography, such as the side walls of trenches. The National Aeronautics and Space Administration (NASA) “Lunabotics” robotic mining competition (RMC) is a university-level competition designed to engage and retain students in science, technology, engineering, and mathematics (STEM). NASA has directly benefited from the competition by encouraging the development of innovative lunar excavation concepts from universities which has resulted in clever ideas and solutions which could be applied to an actual lunar excavation device or payload. The challenge is for students to design and build a remote controlled or autonomous excavator, called a “lunabot”, which can collect and deposit a minimum of 10 kg of lunar simulant within 15 min. In recent years, the goal has been changed to excavate a minimum of 1 kg of simulated icy regolith which is found under an overburden of regolith simulant. The complexities of the challenge include the abrasive characteristics of the lunar regolith simulant, the weight and size limitations of the lunabot, and the ability to control the lunabot from a remote-control center or operate it autonomously. This paper will present the results of the ten Lunabotics Robotic Mining Competitions held between May 2010 and May 2019. Each year over 50 university teams have attended, resulting in over 500 lunabot designs and subsequent prototypes. Over 6,000 university students have been part of the on-site competition at KSC. Even more students and the public were engaged via internet broadcasting and social networking media. The various designs have been cataloged and categorized here to provide information to future Lunabotics RMC mining robot designers and competitors. Categories will focus on both the mechanical design as well as the autonomy architecture/design. It is also expected to be of value for actual future space missions, as knowledge is gained from testing many innovative prototypes in simulated lunar regolith. A taxonomy of robotic excavator designs has been presented. In addition, the paper will discuss changes in learning paradigms occurring in the current generation of students, and how this competition leverages those changes to challenge students to develop skills in graduate level concepts and apply them. Examples of how this translates to hiring opportunities for commercial sponsors have also been discussed.} } - Stoeser, D. B., Rickman, D. L. and Wilson, S. A. (2010). Preliminary Geological Findings on the BP-1 Simulant
. NASA, NASA/TM-2010-216444. Source
BibTeX
@techreport{stoeser2010preliminary, title = {Preliminary Geological Findings on the BP-1 Simulant}, author = {Stoeser, D. B. and Rickman, Douglas L. and Wilson, Sharon A.}, number = {NASA/TM-2010-216444}, institution = {NASA}, year = {2010}, url = {https://ntrs.nasa.gov/citations/20100036344}, abstract = {A waste material from an aggregate producing quarry has been used to make an inexpensive lunar simulant called BP-1. The feedstock is the Black Point lava flow in northern Arizona. Although this is part of the San Francisco volcanic field, which is also the source of the JSC-1 series feedstock, BP-1 and JSC-1 are distinct. Chemically, the Black Point flow is an amygdaloidal nepheline-bearing basalt. The amygdules are filled with secondary minerals containing opaline silica, calcium carbonate, and ferric iron minerals. X-ray diffraction (XRD) detected approximately 3% quartz, which is in line with tests done by the Kennedy Space Center Industrial Hygiene Office. Users of this material should use appropriate protective equipment. XRD also showed the presence of significant halite and some bassanite. Both are interpreted to be evaporative residues due to recycling of wash water at the quarry. The size distribution of BP-1 may be superior to some other simulants for some applications.} } - Dotson, B., Sanchez Valencia, D., Millwater, C., Easter, P. B., Long-Fox, J., Britt, D. and Metzger, P. (2024). Cohesion and Shear Strength of Compacted Lunar and Martian Regolith Simulants
. Icarus. Source
BibTeX
@article{dotson2024cohesion,
  title = {Cohesion and Shear Strength of Compacted Lunar and Martian Regolith Simulants},
  author = {Dotson, Brandon and Sanchez Valencia, D. and Millwater, C. and Easter, Parks B. and Long-Fox, J. and Britt, D. and Metzger, P.},
  journal = {Icarus},
  volume = {411},
  pages = {115943},
  year = {2024},
  doi = {10.1016/j.icarus.2024.115943}
}