NASA JSC Planetary Analog Test Site
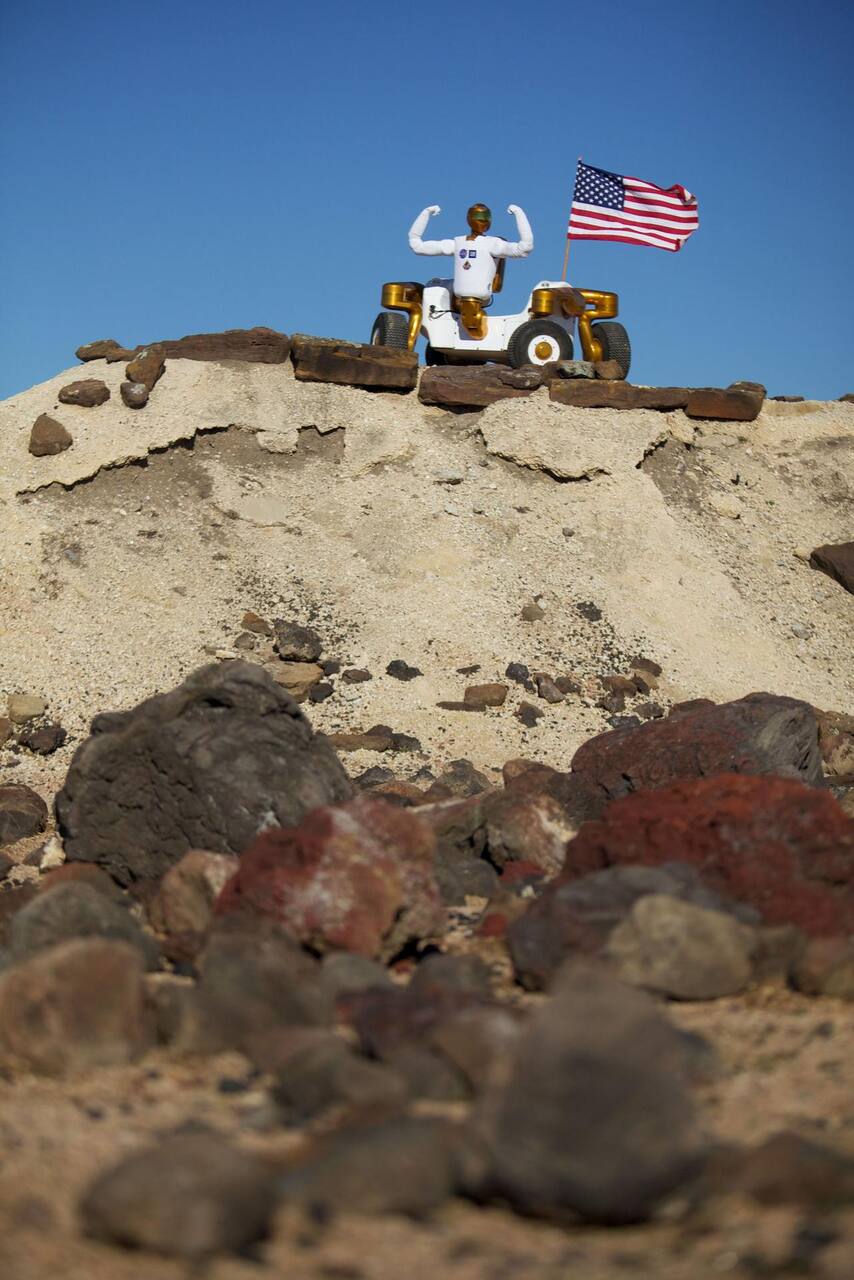
Joseph Bibby. Public domain (NASA / US government work).
The Planetary Analog Test Site at NASA JSC, universally called the Rock Yard, is an outdoor multi-acre terrain field in five named areas, built for integrated tests that put crew, suits, rovers and robots on the same terrain at the same time [1]. The five areas are the Mars Yard, the Mt Kosmo hill, the Lunar Yard with its three craters, the Sand Pit and the Cat Box, and each is a capability section below.
Three of the five sit on a sprayed concrete underlay, so most of the site is a made surface rather than a deformable soil bed. Nothing on it is a lunar or Martian simulant, and there is no vacuum, no thermal control and no gravity offload outdoors. The indoor JSC facilities that cover those cases sit in other buildings under other organizations.
A 2025 NASA survey of planetary rover mobility test practice places outdoor terrain fields like this one alongside indoor soil bins and single-wheel test rigs as one leg of a mobility test program, useful for geometry, obstacle negotiation and operations rehearsal but not for the bearing-capacity and slip measurements a controlled soil bed is built to produce [7]. Other national programs have built comparable outdoor fields for the same integrated purpose: DLR’s Moon-Mars Test Site, for example, pairs a similar strewn-terrain area with instrumentation the Rock Yard does not have, an explicit point of contrast rather than a shared design [8].
Laboratory data
Section titled “Laboratory data”| Parameter | Value |
|---|---|
| Operator | NASA JSC |
| Location | Houston, Texas, United States |
| Commissioned | Not published. In documented rover use by at least 2015 |
| Type | Outdoor analogue terrain field in five named areas |
| Floor area | Multi-acre; the five areas total roughly 6,000 m2 as dimensioned |
| Capabilities | Mars Yard, Mt Kosmo, Lunar Yard, Sand Pit, Cat Box |
| Simulant or terrain | Crushed limestone, decomposed granite, Blackstar granite, basalt, sand, gravel |
| Instrumentation | None installed. Slope maps and Gazebo world models available for some areas |
| Ground truth | Not published. No independent position measurement described |
| Fidelity limits | No simulant, no vacuum, no thermal control; three areas on sprayed concrete |
| Access | Test planning, consultation and integration offered as a service; no lead time published |
| Cited by | Robonaut 2 on Centaur 2, Resource Prospector [3], PUFFER [9] |
Source: [1].
Capabilities
Section titled “Capabilities”Working volumes, slopes and materials for all five areas below come from the operator’s own facility description [1] unless a source is stated otherwise.
Mars Yard
Section titled “Mars Yard”| Parameter | Value |
|---|---|
| Working volume | Approximately 40 x 45 m |
| Test article limits | Suited subjects, Centaur 2 and the RP15 rover run to date [3] |
| Vacuum | Not applicable. Outdoors at ambient pressure |
| Temperature | Not controlled. Houston outdoor conditions |
| Illumination | Not applicable. Terrestrial sky; low-light work is done at night |
| Simulant or terrain | Stabilized crushed limestone and decomposed granite, strewn basaltic rock |
| Slope | Level. Graded slopes are at Mt Kosmo |
| Gravity offload | Not available outdoors. Full Earth weight |
| Instrumentation | None installed. Slope map and Gazebo world model available |
The Mars Yard is the reference surface for the site: a stabilized crushed limestone and decomposed granite base covered with strewn basaltic rocks, over an underlay of sprayed concrete. The Resource Prospector team, describing the same yard from a user’s side, gives its rocks as 0.05 m to 1.0 m in height [3].
Mt Kosmo
Section titled “Mt Kosmo”| Parameter | Value |
|---|---|
| Working volume | Approximately 30 x 43 m, summit about 7 m above the Mars Yard |
| Temperature | Not controlled. Houston outdoor conditions |
| Simulant or terrain | Same as the Mars Yard, over sprayed concrete stabilizing the slopes |
| Slope | Approaches from 15 to over 30 degrees, fixed by construction |
| Gravity offload | Not available. A rover climbs at full Earth weight |
| Instrumentation | None installed |
Mt Kosmo is the only graded terrain on the site, and its slopes are set by construction rather than adjustable. The sprayed concrete underlay is there to hold the slopes in place, which also means a climb on it is a climb on a made road. The Resource Prospector description of the site gives a 5 m tall hill and slopes from flat to 20 degrees [3], both lower than the operator’s own figures; neither document reconciles the two.
Lunar Yard
Section titled “Lunar Yard”| Parameter | Value |
|---|---|
| Working volume | Approximately 40 x 40 m, with three representative lunar craters |
| Temperature | Not controlled. Houston outdoor conditions |
| Simulant or terrain | Stabilized crushed limestone covered with Blackstar granite, over sprayed concrete |
| Slope | Crater walls only; angles and crater dimensions not published |
| Gravity offload | Not available. Full Earth weight |
| Instrumentation | None installed |
The Lunar Yard swaps the Mars Yard’s basaltic surface cover for Blackstar granite and adds the three craters. Crater diameters and depths are not published, and the granite is a terrestrial aggregate rather than a lunar simulant.
Sand Pit
Section titled “Sand Pit”| Parameter | Value |
|---|---|
| Working volume | Approximately 15 x 30 m; depth not published |
| Simulant or terrain | Masonry sand over local soil, mostly unconsolidated clay |
| Gravity offload | Not available. Full Earth weight |
| Instrumentation | None installed |
One of the two deformable areas on the site, and the only one described purely as sand. No depth, relative density target or preparation procedure between tests is published.
Cat Box
Section titled “Cat Box”| Parameter | Value |
|---|---|
| Working volume | Approximately 14 x 50 m; depth not published |
| Simulant or terrain | Coarse gravel with masonry sand at one end, over local soil |
| Slope | Set by sculpting; range not published |
| Gravity offload | Not available. Full Earth weight |
| Instrumentation | None installed |
The Cat Box is the reconfigurable area: the only one the operator describes as supporting limited sculpting into various terrain, which makes it the place where a specific crater, berm or trench geometry can be built for a campaign.
Instrumentation
Section titled “Instrumentation”The published facility description lists terrain data as an available product rather than instrumentation as an installed capability: slope maps and Gazebo world models exist for some areas. No permanent motion capture, total station or load instrumentation is described for any of the five areas, unlike the Glenn and Kennedy soil bins, so a slip or sinkage measurement made here rests on the article’s own sensing.
Site support is 110 V and 220 V AC electrical power, the latter on an SS2-50R outlet, a climate-controlled work and mission support area with 110 V power, limited non-climate-controlled storage during testing, pop-up shade canopies, and space suit hardware and test subject support on an as-required cost basis [1].
What it does not reproduce
Section titled “What it does not reproduce”Deformable terrain, over most of the site. Three of the five areas sit on a sprayed concrete underlay beneath a stabilized aggregate base. Sinkage, slip and drawbar pull on those surfaces are properties of a made road, not of regolith. The Sand Pit and Cat Box are the exceptions, and the Cat Box is the only area described as reconfigurable.
Regolith of any kind. The listed materials are crushed limestone, decomposed granite, Blackstar granite, basalt, masonry sand, coarse gravel and local clay. No lunar or Martian simulant appears in the facility description, and no preparation or density control procedure is published, which is the structural difference between this site and the GMRO bins or the Glenn SLOPE lanes.
Lighting. The site is outdoors under Earth’s sky and atmosphere. Low solar elevation and the hard shadow of the lunar south pole are not producible; night operations are the substitute, and the lunar lighting problem is addressed instead in the rendered visual model driving the B16 motion table described below [2].
Gravity. Nothing outdoors offloads. A rover driving the Mars Yard or climbing Mt Kosmo does so at full Earth weight.
Weather. Houston conditions apply. The published service list offers pop-up shade canopies and a climate-controlled support area, which locates the problem.
Campaigns run there
Section titled “Campaigns run there”Resource Prospector RP15 distributed operations, 2015. RP15 was a Phase A engineering test unit taken from concept to a rover driving in the lunar analogue Rock Yard within a single year [3]. The point of running it there was to validate fully distributed operations: the driver and co-driver worked from Ames, rover systems from Johnson and payload operations from Kennedy, with command allocations refined through fortnightly procedural simulations that began on paper and voice calls and then added data from a processor-in-the-loop rig. The rover was driven by waypoints, sized against an expected round trip command and control time of six to over 25 seconds for the flight mission [3]. Its flight software was built on NASA’s Core Flight Software, and the 2015 build 1 provided hardware interfaces, basic mobility, waypoint driving, odometry and inertial measurement unit localization, basic error checking and camera services. The team records that the rover was capable of operating in the yard by day and by night [3].
Robonaut 2 on Centaur 2, February 2011. The Centaur 2 wheeled base, derived from lessons learned on the Space Exploration Vehicle, was integrated with Robonaut 2 and run at the Planetary Analog Test Site [1]. The Space Exploration Vehicle lineage is itself a wheeled chassis under a reconfigurable upper body, the same layout description JSC used for ATHLETE’s own “Centaur-like” cargo variant, a humanoid torso on a wheeled frame built for a different mission [10].
PUFFER mapping trials. JPL’s Pop-Up, Flat-Folding Explorer Rovers ran autonomous mapping trials at the Mars Yard, using multiple trails through the strewn rock to evaluate mapping performance on the same terrain the operator catalogs here [9].
Other NASA JSC facilities named in the same catalog
Section titled “Other NASA JSC facilities named in the same catalog”The NASA JSC analogs and mockups catalog that describes the Rock Yard also lists several indoor facilities [1], and a 2024 full paper describes a further one [2]. They sit in different buildings under different organizations, they are not part of this test site, and none of them has a published description detailed enough to carry a laboratory page of its own yet, so their figures are recorded here in prose.
NASA. Public domain (NASA / US government work).
Chamber B is the human-rated thermal vacuum capability: an internal volume 7.6 m (25 ft) in diameter by 7.9 m (26 ft), a pressure range from 1 x 10^-6 torr to 760 torr and a low temperature range of -300 F, with a traversing monorail that provides weight relief to one suited crew member at a time and dual crew airlocks for access and for moving test crew in and out during a test [1]. The facility’s own test planning guide frames the chamber as a service offered to both NASA and commercial hardware and software customers, with a stated roadmap of milestones, roles and required inputs rather than a fixed price list [4].
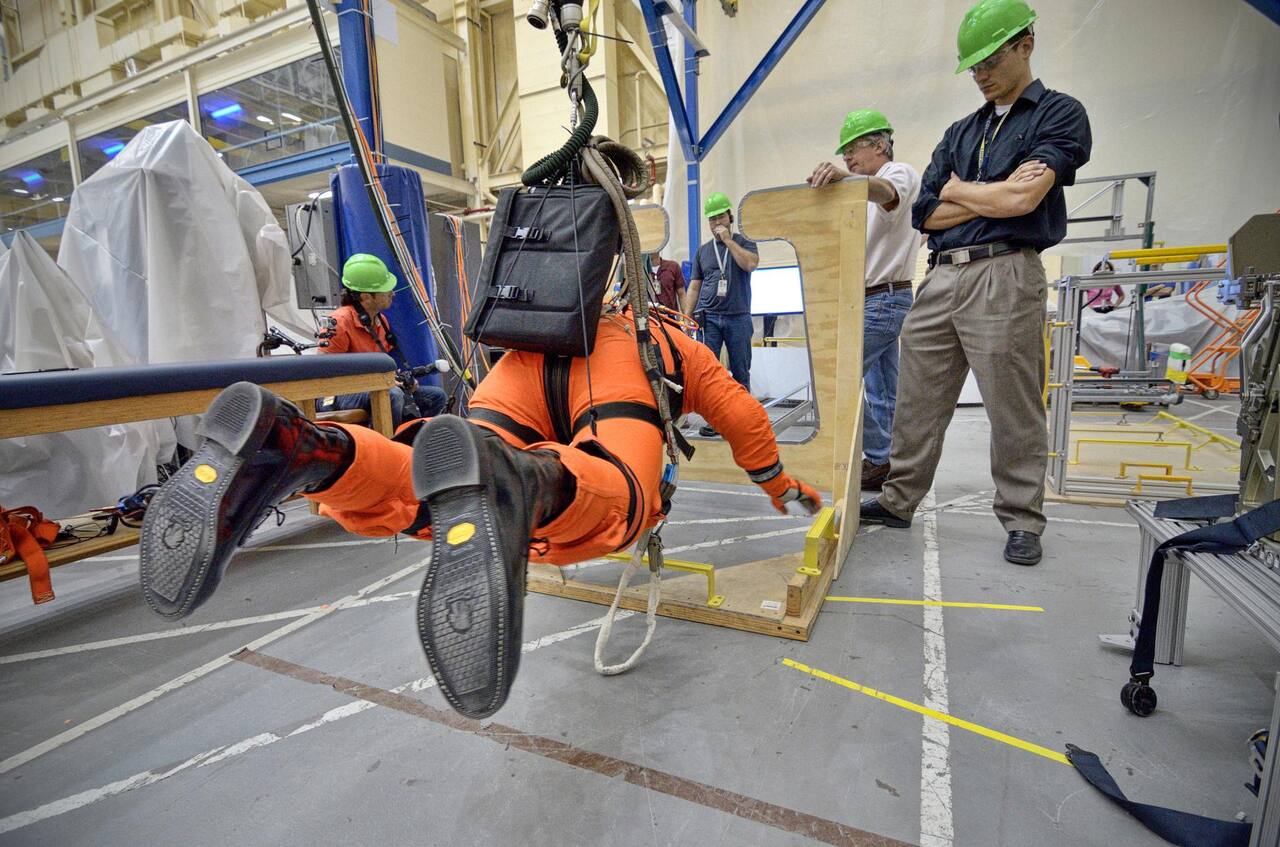
ARGOS, the Active Response Gravity Offload System, has its own page: NASA JSC Active Response Gravity Offload System. It is an overhead bridge crane arrangement 41 x 24 x 25 ft overall giving a 13 x 30 x 15 ft workspace at 750 lb offload capability, with gimbal payload interfaces for suited, unsuited and unmanned articles, pressurized breathing air, suit cooling water and AIBEL motion tracking [1]. A companion paper on characterizing the suit-side gimbal describes fourteen subjects used to locate the pivot point against each subject’s suited center of gravity, since a pivot point set even slightly off that point produces a righting moment that makes the rig artificially stable or artificially unstable [5]. The same offload problem, tracking a moving article on two horizontal axes rather than fixing it under one overhead crane, has been attempted on a smaller scale with an infrared-tracked counterweight rig built for rover testing at a different laboratory, evidence that JSC’s overhead-crane geometry is one of more than one way to cancel inertial and friction forces during a reduced-gravity test [6].
The Partial Gravity Simulator is servos, air bearings and gimbals providing reduced gravity simulation for astronaut training, task evaluation and EVA equipment development [1]. The Precision Air Bearing Floor is a flat, smooth surface giving two-dimensional frictionless motion to large articles floated on perforated pads over a cushion of compressed air, for rendezvous and contact testing and low or zero g mass handling. The Building 360 Lunar Development and Dust Containment Room covers dust work [1].
The B16 six degree of freedom motion table is the newest addition. Installed in the B16 Mini Dome at the Systems Engineering Simulator and commissioned by Mikrolar in January 2023, it carries 2,500 lb on a 69.25 in platform with plus or minus 25 in of horizontal travel, plus or minus 12 in vertical, plus or minus 28 degrees of roll, pitch and yaw, and 1 mm repeatability and accuracy across all six axes, with mechanical brakes on every axis [2]. It drives a lunar south pole visual model built on the Trick simulation framework with a multibody dynamic model of the Lunar Terrain Vehicle front-entry reference design, NASA JSC Engineering Orbital Dynamics model, a nodal electrical power system model in GUNNS, and a contact model, so that a shirt-sleeve subject on the platform feels the physical consequence of driving the simulated rover [2].
It was used in 2022 and 2023 for a preliminary handling qualities study of the LTV front-entry reference design, with a shirt-sleeve subject on the platform driving through a virtual reality view of the lunar south pole [2]. Drivers reported that braking stopped the vehicle quickly, with some describing it as abrupt, twitchy and harsh, and some observed that the one-sixth g environment affected stopping distance. The stated rationale for building it is that the only other lunar rover motion simulator was a modified US Air Force SMK23 flight simulator built at Marshall in the late 1960s, which ran a moving map of a smooth Maria area under a television camera, and that no other lunar surface simulator with these capabilities exists [2]. The LTV that the motion table drives is the same vehicle class a 2025 NASA mobility survey uses as its case study for identifying the test gaps a wheeled lunar rover still has to close, tires and mobility hardware rather than driver handling [7].
What is not established
Section titled “What is not established”Nothing on the outdoor site is a measurement rather than a description: no grain size distribution, bulk density, cohesion, friction angle or bearing capacity is published for any of the five areas, and no preparation, raking or compaction procedure between runs is stated. The site’s own figures disagree on scale, calling itself a multi-acre field in one place and a quarter acre in another, and no accuracy, resolution or survey method is given for the slope maps and Gazebo world models it does offer [1]. The B16 motion table’s handling qualities results are a simulation’s answers, not a rover’s: the terramechanics model computes only compression, bulldozing and lumped rolling resistance under uniform soil properties, half the test drivers showed simulator sickness symptoms and five of thirteen did not finish the traverse, and a table angle discrepancy ran one task at 15 degrees rather than the intended 20 without being noticed until after the fact [2]. Resource Prospector’s RP15 distributed-operations run predates the program’s 2018 cancellation and reports no drilling, water-detection or traverse performance, only that the rover operated [3]. ARGOS’s own documentation gives no offload force accuracy, bandwidth, residual horizontal force or cable-angle error for its overhead crane, so the rig’s fidelity as a gravity analog has no published error bar even where a pivot point has been characterized against a subject’s center of gravity [1][5].
References
- NASA Johnson Space Center. (2024). JSC Analogs and Mockups. nasa.gov/reference/jsc-analogs-mockups
BibTeX
@misc{nasajscanalogs, title = {JSC Analogs and Mockups}, author = {{NASA Johnson Space Center}}, organization = {nasa.gov}, year = {2024}, url = {https://www.nasa.gov/reference/jsc-analogs-mockups/} } - Litaker, H. L. J., Vos, G. A., Lieberman, A. P., Bingham, L. K., Cramer, M. O., Gelo, T. J., Scharunovych, N., Frangoudis, A. A., Royer, J. M. and Jones, V. L. (2024). Developing a Motion-Based System for Lunar Vehicle Handling Qualities Testing
. IEEE Aerospace Conference, 20230013022. Source
BibTeX
@inproceedings{litaker2024developing, title = {Developing a Motion-Based System for Lunar Vehicle Handling Qualities Testing}, author = {Litaker, Harry L., Jr. and Vos, Gordon A. and Lieberman, Asher P. and Bingham, Lee K. and Cramer, Mark O. and Gelo, Terence J. and Scharunovych, Nadia and Frangoudis, Athena A. and Royer, Jeffrey M. and Jones, Vanessa L.}, booktitle = {IEEE Aerospace Conference}, number = {20230013022}, pages = {1-22}, institution = {NASA}, year = {2024}, doi = {10.1109/aero58975.2024.10521283}, abstract = {Motion and visual cue influences are critical in any simulator system, as they impact multiple aspects of the human’s neurovestibular and visual systems. Cues of real motion proceeds to the brain before cues of visual change. It is important therefore for simulator motion cues to exist and to match those realistically with those of the real vehicle to provide transferable training of the activity for operations. The United Kingdom’s Royal Air Force Institute of Aviation Medicine (1989)[1] stated that motion platforms are the only simulation devices capable of fully stimulating the body motion sensors. They confirmed that motion platforms can impart accelerations to the whole body and therefore exercise the automatic motion feedback-loop that operators are used to. With both visual and motion cues handling the vehicle becomes more realistic. Strachan (2019)[1] confirms motion cueing from a well set-up motion platform has been found to be important especially in conditions such as night or reduced visibility where motion cues may be more relied upon. As of this writing, the only lunar rover motion simulator is housed at the General Motors (GM) Milford Proving Ground, which only simulates the motions of a traditional car. A NASA Test Team proposed to complete a motion-based simulation system for NASA’s Lunar Terrain Vehicle (LTV) which resides at Johnson Space Center’s Systems Engineering Simulator facility. This activity integrated existing fixed base simulation capabilities with a newly procured six-degree of freedom motion base platform for the design, development, evaluation, and training associated with the LTV project. This would incorporate a South Pole Lunar virtual reality simulation using Lunar Reconnaissance Orbiter 5m/pixel high-resolution imagery and Unreal 5.2 Virtual Shadow Maps, combined with a virtual reality (VR) headset, integrated within a rover cockpit on a Mikrolar Motion Platform for evaluating human performance and vehicle handling qualities for concept roving vehicle designs. The motion-based system received its Human Rating Certification on March 2023. To begin testing the new facility, a preliminary handling qualities study was conducted. The objectives were to determine if there is a correlation amongst three handling quality methods of performance for a lunar vehicle and to understand the effects of a simulated 1/6-g loads and visuals with a motion platform on the operator while in a 1-g physical environment. The capability this system provides directly benefits the NASA’s Extravehicular Activity and Human Surface Mobility Program and NASA’s Flight Operations Directorate in evaluating the driving qualities of vehicle concepts, human performance related to the operating of a lunar surface vehicle, and assessment of suit related driving impacts. It would also provide direct operational benefit by providing a first-in-class and unique simulation platform for the lunar astronaut training curriculum. The empirical knowledge of rover and human performance on this scale is paramount as there is currently no other lunar surface simulator with these capabilities. The result of this study ensures a broadly applicable method of testing for shirtsleeve, unpressurized and pressurized suited rover handling qualities.} } - Andrews, D., Colaprete, A., Quinn, J., Bluethmann, W. and Trimble, J. (2015). Resource Prospector (RP) - Early Prototyping and Development
. AIAA SPACE Conference and Exposition, 20150018395. Source
BibTeX
@inproceedings{andrews2015resource, title = {Resource Prospector (RP) - Early Prototyping and Development}, author = {Andrews, Dan and Colaprete, Anthony and Quinn, Jacqueline and Bluethmann, William and Trimble, Jay}, booktitle = {AIAA SPACE Conference and Exposition}, number = {20150018395}, publisher = {American Institute of Aeronautics and Astronautics}, institution = {NASA}, address = {Pasadena, California}, year = {2015}, doi = {10.2514/6.2015-4460}, abstract = {The Resource Prospector (RP) is an In-Situ Resource Utilization (ISRU) technology demonstration mission under study by the NASA Human Exploration and Operations Mission Directorate's (HEOMD) Advanced Exploration Systems (AES) Division. The mission, currently planned to launch in 2020, will demonstrate extraction of oxygen from lunar regolith to validate ISRU capability. The mission will address key Strategic Knowledge Gaps (SKGs) for robotic and human exploration to the Moon, Near Earth Asteroids (NEAs), and ultimately Mars, as well as meet the strategic goals of the Global Exploration Roadmap (GER), offered by the International Space Exploration Coordination Group (ISECG). In this roadmap, the use of local resources is specifically addressed relating to human exploration. RP will provide knowledge to inform the selection of future mission destinations, support the development of exploration systems, and reduce the risk associated with human exploration. Expanding human presence beyond low-Earth orbit to asteroids and Mars will require the maximum possible use of local materials, so-called in-situ resources. The moon presents a unique destination to conduct robotic investigations that advance ISRU capabilities, as well as providing significant exploration and science value. Lunar regolith contains useful resources such as oxygen, water, silicon, and light metals, like aluminum and titanium. Oxygen can be separated from the regolith for life support (breathable air), or used to create rocket propellant (oxidizer). Regolith can be used to protect against radiation exposure, be processed into solar cells, or used to manufacture construction materials such as bricks and glass. RP will characterize the constituents and distribution of water and other volatiles at the poles of the Moon, enabling innovative uses of local resources, in addition to validating ISRU capabilities. This capability, as well as a deeper understanding of regolith, will be valuable in the exploration of near-Earth asteroids (NEAs) and Mars. In order to reduce risk and explore system designs, the RP project is attempting two-fold approaches to development as it looks towards flight. We continue to explore flight planning, requirements, and interfaces definition by using Engineering Test Units (ETUs), looking towards lunar deployment, while also using fiscal year 2015 to develop, build and test an earth-terrestrial prototype rover and payload system. This terrestrial prototype, called "RP15", is built to both inform the system design, and to be a partnership advocacy tool for this unique mission. RP15 must be affordable within the resource and time constraints of fiscal year 2015, while working to the following Needs, Goals, and Objectives provided by HEOMD/AES: 1. Demonstrate rover mobility in a 1g environment 2. The Surface Segment (prototype rover + payload system) shall represent the flight system concept with as much fidelity as affordable (limited by cost and schedule) - Surface Segment shall be the approximate size/dimension/footprint -Surface Segment shall package all the expected devices (instruments, systems, etc.), even if some facets are mocked-up due to time/cost constraints -Overall Surface Segment fidelity negotiable to make achievable 3. Priority should be given to illustrating mission functionality over support functionality, which exists solely to support mission functionality This paper will provide an overview of RP project developments, including the design and build, capturing the development and initial integrated testing of RP15 in relevant environments.} } - Montz, M. and Trevino, L. (2012). Chamber B Thermal/Vacuum Chamber: User Test Planning Guide
. NASA Johnson Space Center, 20120003246. Source
BibTeX
@techreport{montz2012chamber, title = {{Chamber B} Thermal/Vacuum Chamber: User Test Planning Guide}, author = {Montz, Michael and Trevino, Louis}, number = {20120003246}, institution = {NASA Johnson Space Center}, year = {2012}, url = {https://ntrs.nasa.gov/citations/20120003246}, abstract = {Test process, milestones and inputs are unknowns to first-time users of Chamber B. The User Test Planning Guide aids in establishing expectations for both NASA and non-NASA facility customers. The potential audience for this guide includes both internal and commercial spaceflight hardware/software developers. It is intended to assist their test engineering personnel in test planning and execution. Material covered includes a roadmap of the test process, roles and responsibilities of facility and user, major milestones, facility capabilities, and inputs required by the facility. Samples of deliverables, test article interfaces, and inputs necessary to define test scope, cost, and schedule are included as an appendix to the guide.} } - Jarvis, S. L., Vu, L. Q., Gupta, G., Benson, E., Kim, K. H., Rhodes, R. and Rajulu, S. L. (2023). Development of ARGOS (Active Response Gravity Offload System) Offloading Assessments and Methodology for Lunar EVA Simulations
. International Conference on Environmental Systems, 20230002430. Source
BibTeX
@inproceedings{jarvis2023development, title = {Development of ARGOS (Active Response Gravity Offload System) Offloading Assessments and Methodology for Lunar EVA Simulations}, author = {Jarvis, Sarah L. and Vu, Linh Q. and Gupta, Garima and Benson, Elizabeth and Kim, K. Han and Rhodes, Richard and Rajulu, Sudhakar L.}, booktitle = {International Conference on Environmental Systems}, number = {20230002430}, institution = {NASA}, address = {Calgary}, year = {2023}, url = {https://ntrs.nasa.gov/citations/20230002430}, abstract = {The Active Response Gravity Offload System (ARGOS) at NASA Johnson Space Center (JSC) is an analog environment that can offload pressurized suited subjects for various reduced gravity simulations. The suit is suspended from a robotic overhead crane by a cable connected to the suit via a gimbal with an adjustable pivot point (i.e. offload attachment). There has been increased interest in providing planetary pressurized suited training at ARGOS in preparation for lunar missions. Determination of the appropriate gimbal pivot point location for a given subject is vital for a high-fidelity functional lunar simulation. Interactions between the pivot point location and human-spacesuit center of gravity (CG) can result in righting moments that may lead to artificially stable or unrealistically challenging configurations. Changing the pivot point location is time consuming and repeated adjustment can result in loss of valuable pressurized suited time. This paper aims to share knowledge obtained from the offloading characterization efforts during pressurized suited testing at ARGOS and document the ongoing process to define an appropriate pivot point location through iterative quantitative and qualitative assessments. Human-spacesuit CG locations for the ARGOS lunar simulation were estimated using a 3D body scan and density model combined with spacesuit hardware CAD and specifications. Early pilot testing of the gimbal revealed that setting the pivot point coincident with the modeled CG location was not always possible due to the current gimbal design, and small pivot point shifts had noticeable effects on subject stability. Fourteen subjects performed a series of CG-related tasks in the Exploration Extravehicular Mobility Unit (xEMU) to assess simulation characteristics. Through iterative testing, this task list evolved to streamline the process needed to efficiently identify a suitable pivot point for a given subject. The developed methodology will be critical for pivot point selection during astronaut training in the ARGOS environment.} } - Wavrunek, T. A. (2021). Active Gravity Offloading System with Infrared Tracking for Rover Testing
. Michigan Technological University. Source
BibTeX
@mastersthesis{wavrunek2021active, title = {Active Gravity Offloading System with Infrared Tracking for Rover Testing}, author = {Wavrunek, Travis A.}, publisher = {Michigan Technological University}, school = {Michigan Technological University}, type = {Master of Science report, Mechanical Engineering}, year = {2021}, doi = {10.37099/mtu.dc.etdr/1213}, abstract = {Gravity offloading is a tool used to test how different gravitational forces will impact the mobility of rovers bound for Lunar or Martian expeditions. Previous approaches have been successful in simulating partial gravity environments, and this report details how the Infrared- Gravity offload (IRGO) system, developed for the Planetary Surface Technology Development Laboratory (PSTDL) and lunar simulant sandbox, has a similar aim. Through a series of iterations, IRGO has been developed to actively track an infrared beacon and follow a rover within the test chamber to eliminate inertial and friction forces along two horizonal axes. A portion of a rover’s weight is offloaded using a passive counterweight system to provide a third translational degree of freedom. Future plans to incorporate a lightweight gimbal as well as an active vertical axis are also discussed as solutions to improving the IRGO system.} } - Creager, C., Breckenridge, J., Johnson, K., Oravec, H., Moreland, S., Sobey, A. and McBryan, E. (2025). Best Practices for the Testing of Planetary Roving Vehicle Mobility Systems and Tires
. NASA, 20250003470. Source
BibTeX
@techreport{creager2025best, title = {Best Practices for the Testing of Planetary Roving Vehicle Mobility Systems and Tires}, author = {Creager, Colin and Breckenridge, John and Johnson, Kyle and Oravec, Heather and Moreland, Scott and Sobey, Alexander and McBryan, Emily}, number = {20250003470}, institution = {NASA}, year = {2025}, url = {https://ntrs.nasa.gov/citations/20250003470}, abstract = {NASA has an extensive history of conducting mobility testing on planetary tires, rovers, and mobility subsystems. This paper contains a summary of the best practices and lessons learned from past test approaches, as well as from relevant test methodologies external to NASA, with a focus on tires and mobility systems. It is intended to be a resource for future planetary rover developments. This document, which will be released in two phases, serves two objectives: 1) compile the existing knowledge of mobility related testing within NASA; and 2) identify major gaps in mobility related test needs and suggest potential paths forward. This first release of the document (early 2025) captures information based on the authors’ existing knowledge and an abbreviated literature review. A more thorough version will be released in late 2025 and will include more information on test methods external to NASA, as well as additional lessons learned through further investigations. The Lunar Terrain Vehicle (LTV) is used as case study to help identify major test needs; however, this document is intended to be applicable to a wide range of potential missions. Though no current mobility standards exist for the testing of planetary tires and mobility subsystems, future motive is to utilize the information from this whitepaper to guide the development of NASA mobility test standards.} } - Görner, M., Cebulsky, J., Dömel, A., Durner, M., Giubilato, R., Kuhne, M., Müller, M. G., Lakatos, K., Lehner, P., Lichtenheldt, R., Rebele, B., Roser, M., Sakagami, R., Scheeler, Y., Schuster, M. J., Schütt, M., Stürzl, W., Vayugundla, M. and Wedler, A. (2024). The DLR Moon-Mars Test Site for Robotic Planetary Exploration
. International Conference on Space Robotics. Source
BibTeX
@inproceedings{goerner2024dlr, title = {The DLR Moon-Mars Test Site for Robotic Planetary Exploration}, author = {Görner, Martin and Cebulsky, Jennifer and Dömel, Andreas and Durner, Maximilian and Giubilato, Riccardo and Kuhne, Moritz and Müller, Marcus G. and Lakatos, Kristin and Lehner, Peter and Lichtenheldt, Roy and Rebele, Bernhard and Roser, Mattias and Sakagami, Ryo and Scheeler, Yunis and Schuster, Martin J. and Schütt, Manuel and Stürzl, Wolfgang and Vayugundla, Mallikarjuna and Wedler, Armin}, booktitle = {International Conference on Space Robotics}, pages = {245-252}, institution = {DLR Institute of Robotics and Mechatronics}, year = {2024}, doi = {10.1109/isparo60631.2024.10687411}, abstract = {Building robots for planetary exploration missions requires intensive testing throughout all phases of the design process. Especially, during hard- and software development as well as mission training the process benefits of easy-to-access test sites that offer realistic conditions. For this purpose we have built the 1500 m2DLR Moon-Mars test site in Oberpfaffenhofen, Germany. The facility provides a large variety of geological formations and ground substrates on a compact terrain as well as a rich set of power and network connections. As a unique feature of the outdoor test site, we prepared a dedicated link to the German Space Operations Center that enables telerobotic experiments from ISS. Furthermore, we provide an optical tracking system for ground truth measurement and control. We describe the design and construction process of the test site and present an overview of its features. Three experiments with our robots LRU1, LRU2 and the Scout rover regarding autonomous navigation and mapping, autonomous manipulation and sampling as well as advanced mobility tests demonstrate the usage of the test site.} } - de la Croix, J.-P. and Karras, J. (2019). Pop-Up, Flat-Folding Explorer Rovers: Meet PUFFER—NASA's Origami Rover. Source
BibTeX
@technical_report{delacroix2019puffer, title = {Pop-Up, Flat-Folding Explorer Rovers: Meet PUFFER—NASA's Origami Rover}, author = {de la Croix, Jean-Pierre and Karras, Jaakko}, year = {2019}, url = {https://dataverse.jpl.nasa.gov/dataset.xhtml?persistentId=hdl:2014/52071} } - Wilcox, B. H. (2010). ATHLETE: Lunar Cargo Handling for International Lunar Exploration
. AIAA Space Conference. Source
BibTeX
@inproceedings{wilcox2010athlete,
  title = {ATHLETE: Lunar Cargo Handling for International Lunar Exploration},
  author = {Wilcox, Brian H.},
  booktitle = {AIAA Space Conference},
  year = {2010},
  url = {https://ntrs.nasa.gov/citations/20150008942},
  abstract = {As part of the Human-Robot Systems Project within the NASA Exploration Technology Development Program, the Jet Propulsion Laboratory is developing a vehicle called ATHLETE: the All-Terrain Hex-Limbed Extra-Terrestrial Explorer. The basic idea of ATHLETE is to have six relatively small wheels on the ends of legs. The small wheels and associated drive actuators are much less massive than the larger wheels and gears needed for an "all terrain" vehicle that cannot "walk" out of extreme terrain. The mass savings for the wheels and wheel actuators is greater than the mass penalty of the legs, for a net mass savings. Starting in 2009, NASA became engaged in detailed architectural studies for international discussions with the European Space Agency (ESA), the Japanese Space Agency (JAXA), and the Canadian Space Agency (CSA) under the auspices of the International Architecture Working Group (IAWG). ATHLETE is considered in most of the campaign options considered, providing a way to offload cargo from large Altair-class landers (having a cargo deck 6+ meters above the surface) as well as offloading international landers launched on Ariane-5 or H-2 launch vehicles. These international landers would carry provisions as well as scientific instruments and/or small rovers that would be used by international astronauts as part of an international effort to explore the moon.Work described in this paper includes architectural studies in support of the international missions as well as field testing of a half-scale ATHLETE prototype performing cargo offloading from a lander mockup, along with multi-kilometer traverse, climbing over greater than 1 m rocks, tool use, etc.}
}